

0.00
0.33
0.66
0.06
0.39
0.72
0.11
0.44
0.77
0.17
0.50
0.83
0.22
0.55
0.88
0.28
0.61
1.00
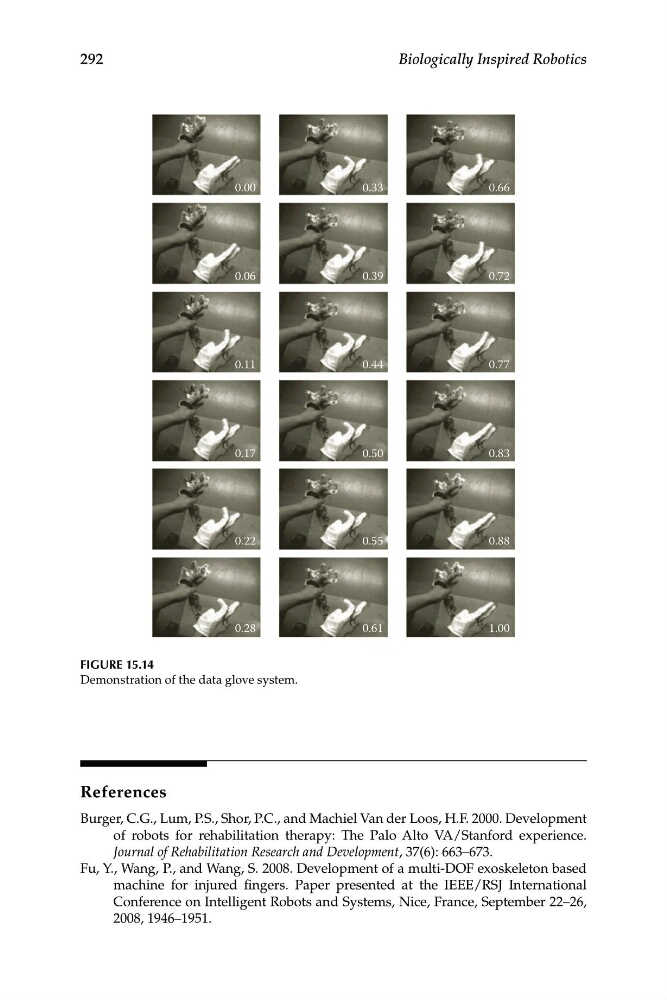
FIGURE 15.14
Demonstration of the data glove system.
292
Biologically Inspired Robotics
References
Burger, C.G., Lum, P.S., Shor, P.C., and Machiel Van der Loos, H.F. 2000. Development
of robots for rehabilitation therapy: The Palo Alto VA/Stanford experience.
Journal of Rehabilitation Research and Development, 37(6): 663–673.
Fu, Y., Wang, P., and Wang, S. 2008. Development of a multi-DOF exoskeleton based
machine for injured fingers. Paper presented at the IEEE/RSJ International
Conference on Intelligent Robots and Systems, Nice, France, September 22–26,
2008, 1946–1951.