

233
Classification of Hand Motion Using Surface EMG Signals
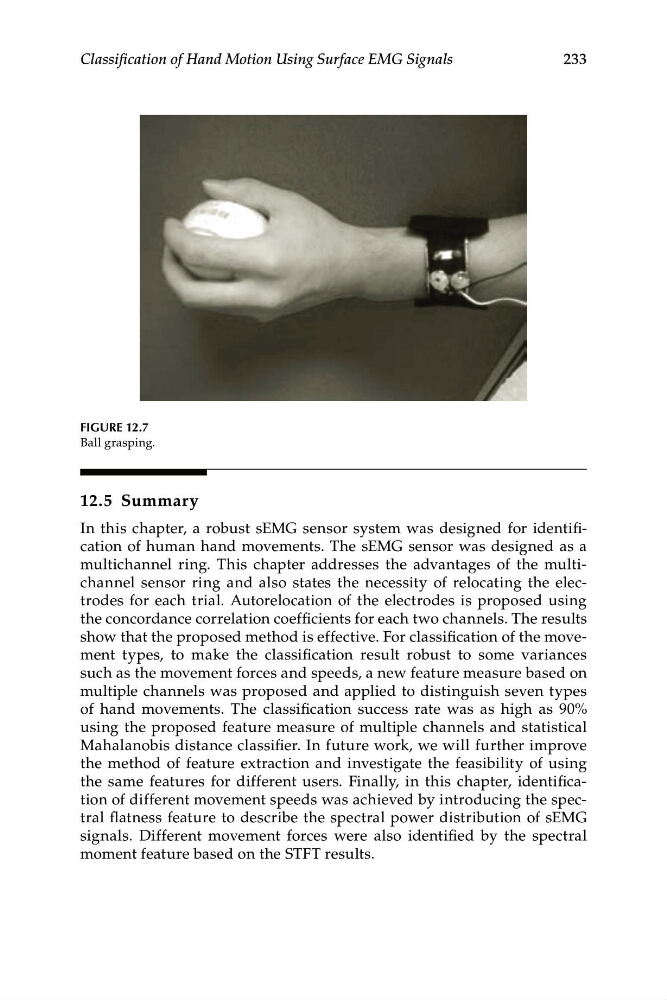
FIGURE 12.7
Ball grasping.
12.5 Summary
In this chapter, a robust sEMG sensor system was designed for identification of human hand movements. The sEMG sensor was designed as a
multichannel ring. This chapter addresses the advantages of the multichannel sensor ring and also states the necessity of relocating the electrodes for each trial. Autorelocation of the electrodes is proposed using
the concordance correlation coefficients for each two channels. The results
show that the proposed method is effective. For classification of the movement types, to make the classification result robust to some variances
such as the movement forces and speeds, a new feature measure based on
multiple channels was proposed and applied to distinguish seven types
of hand movements. The classification success rate was as high as 90%
using the proposed feature measure of multiple channels and statistical
Mahalanobis distance classifier. In future work, we will further improve
the method of feature extraction and investigate the feasibility of using
the same features for different users. Finally, in this chapter, identification of different movement speeds was achieved by introducing the spectral flatness feature to describe the spectral power distribution of sEMG
signals. Different movement forces were also identified by the spectral
moment feature based on the STFT results.