

152
Initial shape
Biologically Inspired Robotics
At point B: ψ ψ
= % , ρ B = r contact ;
At point C: ψ π
= /2 , ρ' = 0 .
where r contact is the contact radius between the cell and the bead.
To solve the equilibrium Equations (8.1) and (8.2), the volume conservation
constraint is imposed (Dao, Lim, and Suresh 2003; Mills et al. 2004; Tan, Sun,
and Huang 2010; Tan et al. 2008, 2009, 2010a, 2010b). Moreover, the contact
radius between beads and RBCs must be known prior by image processing.
In the coordinates defined in Figure 8.1, K 1 , K 2 , ρ, and η can all be expressed as
a function of λ 1 and λ 2 , respectively (see more details in Tan et al. 2008). With
the five equations, that is, Equations (8.1)–(8.3) and the volume conservation
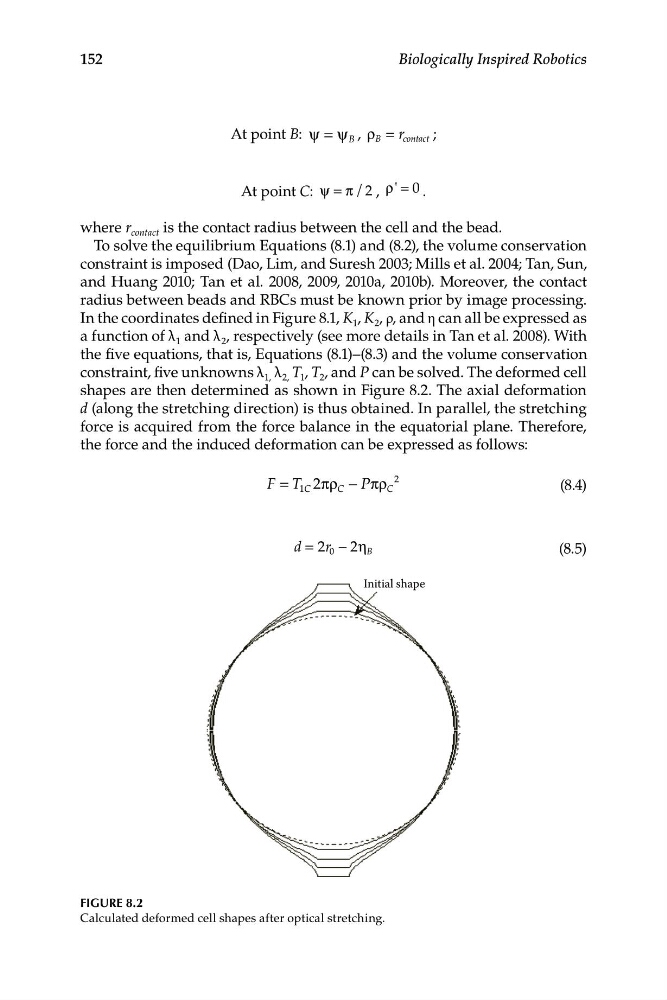
constraint, five unknowns λ 1, λ 2, T 1 , T 2 , and P can be solved. The deformed cell
shapes are then determined as shown in Figure 8.2. The axial deformation
d (along the stretching direction) is thus obtained. In parallel, the stretching
force is acquired from the force balance in the equatorial plane. Therefore,
the force and the induced deformation can be expressed as follows:
F T
= C 2πρ
2
1
C − Pπρ C
(8.4)
d = 2r − 2η
(8
0
B
.5)
FIGURE 8.2
Calculated deformed cell shapes after optical stretching.