

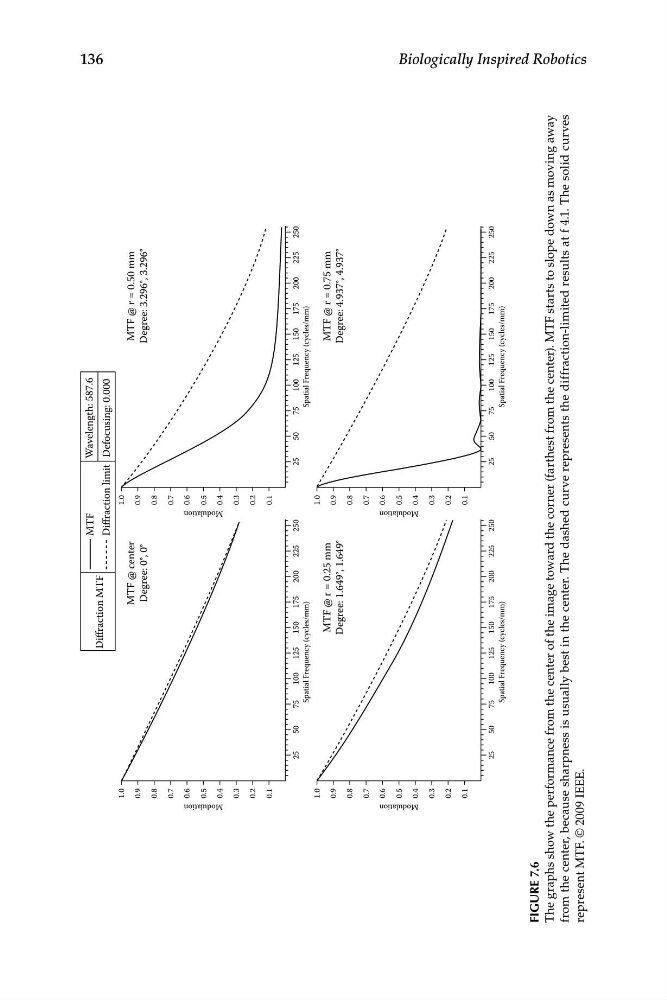
Diffraction MTF
Diffraction limit
MTF
Wavelength: 587.6
Defocusing: 0.000
0.9
0.9
1.0
MTF @ center
Degree: 0°, 0°
1.0
MTF @ r = 0.50 mm
Degree: 3.296°, 3.296°
0.8
0.8
0.7
0.7
Modulation
Modulation
0.6
0.5
0.4
Modulation
Modulation
0.6
0.5
0.4
0.3
0.3
0.2
0.2
0.1
0.1
25
50
75
100
125
150
175
200
225
250
25
50
75
100
125
150
175
200
225
250
Spatial Frequency (cycles/mm)
Spatial Frequency (cycles/mm)
1.0
1.0
0.9
0.9
0.8
0.8
0.6
0.7
MTF @ r = 0.25 mm
Degree: 1.649°, 1.649°
0.7
MTF @ r = 0.75 mm
Degree: 4.937°, 4.937°
0.6
0.5
0.5
0.4
0.4
0.3
0.3
0.2
0.2
0.1
0.1
25
50
75
100
125
150
175
200
225
250
25
50
75
100
125
150
175
200
225
250
Spatial Frequency (cycles/mm)
Spatial Frequency (cycles/mm)
y
s
a
e
w
v
r
a
u
g
n
i
d c
i
v
l
o
o
m
e s
s
h
a
T
n
.
dow
1
e
t f 4.
op
s a
t
l
su
e
s to sl
t
r
d r
a
e
F st
t
i
m
T
i
l
M
.
no
)
i
r
t
e
t
n
rac
e
f
e c
f
i
h
e d
om t
h
s t
t
r
n
st f
e
s
e
e
h
t
pr
r
e
a
f
(
e r
r
v
e
r
n
u
e cor
c
d
h
she
rd t
a
a
e d
w
h
. T
r
e
age to
t
n
m
e
e c
e i
h
h
of t
t
n
r
st i
e
e
t
n
e
y b
e c
l
l
a
h
om t
u
s
u
s
r
s i
e f
s
nc
a
pne
m
r
.
a
for
r
e sh
EEE
e
s
I
e p
u
9
a
0
0
h
c
e
t
w
, b
sho
r
© 2
.
e
F
t
T
n
6
s
e
.
h
M
7
e c
t
p
n
E
a
h
e
R
r
GU
e g
om t
s
e
pr
h
FI
e
T
r
f
r
136
Biologically Inspired Robotics