

GPS
SMS
Comm’s interface.
Forward scanning
sonar array.
Charging socket.
Bootloader switch.
Main power switch.
Batteries
PCB’s
Emergency
Batteries
release
Gumstix
weight
controller.
Compass.
Vertical thruster.
98
Biologically Inspired Robotics
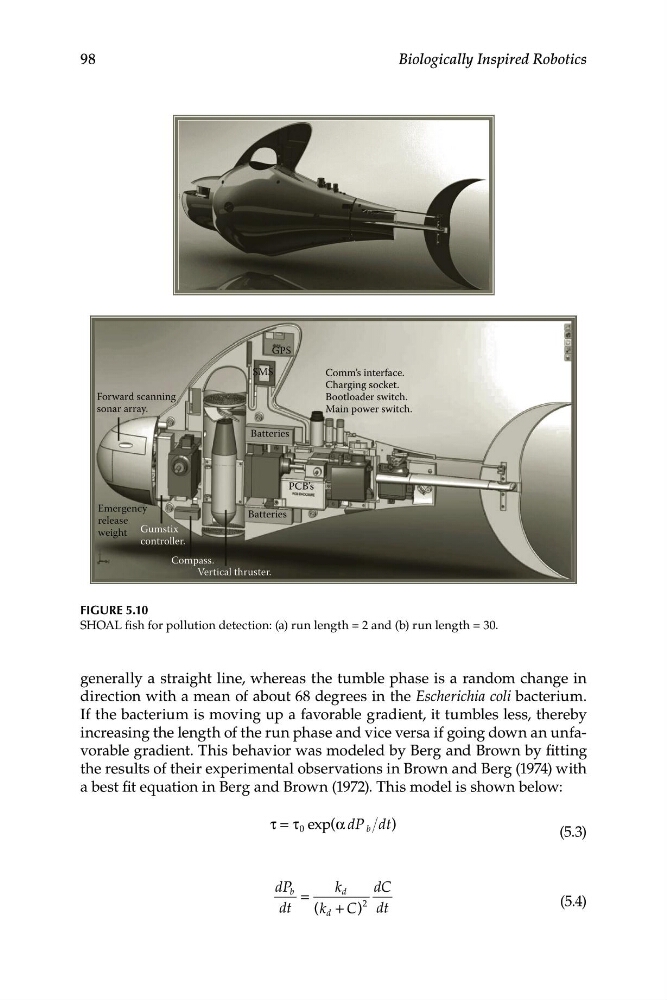
FIGURE 5.10
SHOAL fish for pollution detection: (a) run length = 2 and (b) run length = 30.
generally a straight line, whereas the tumble phase is a random change in
direction with a mean of about 68 degrees in the Escherichia coli bacterium.
If the bacterium is moving up a favorable gradient, it tumbles less, thereby
increasing the length of the run phase and vice versa if going down an unfavorable gradient. This behavior was modeled by Berg and Brown by fitting
the results of their experimental observations in Brown and Berg (1974) with
a best fit equation in Berg and Brown (1972). This model is shown below:
τ τ
= 0 exp(α dP b dt)
(5.3)
dP b
k d
dC
=
)
2
(5.4)
dt
(k d + C dt