

91
A School of Robotic Fish for Pollution Detection in Port
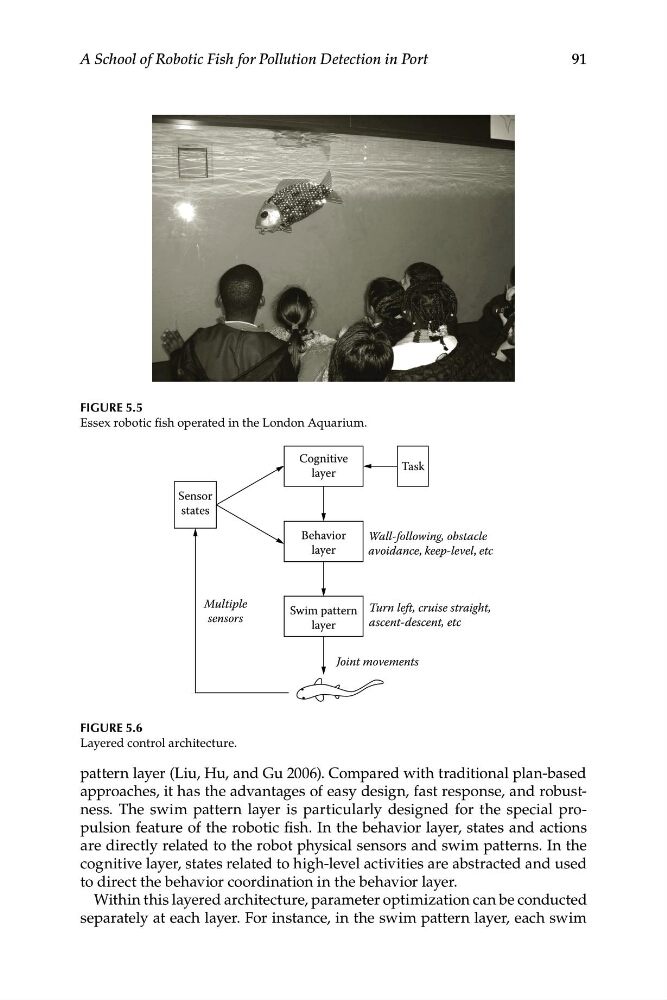
FIGURE 5.5
Essex robotic fish operated in the London Aquarium.
Task
Cognitive
layer
Behavior
layer
Sensor
states
Swim pattern
layer
Multiple
sensors
Wall-following, obstacle
avoidance, keep-level, etc
Turn left, cruise straight,
ascent-descent, etc
Joint movements
FIGURE 5.6
Layered control architecture.
pattern layer (Liu, Hu, and Gu 2006). Compared with traditional plan-based
approaches, it has the advantages of easy design, fast response, and robustness. The swim pattern layer is particularly designed for the special propulsion feature of the robotic fish. In the behavior layer, states and actions
are directly related to the robot physical sensors and swim patterns. In the
cognitive layer, states related to high-level activities are abstracted and used
to direct the behavior coordination in the behavior layer.
Within this layered architecture, parameter optimization can be conducted
separately at each layer. For instance, in the swim pattern layer, each swim