

90
Biologically Inspired Robotics
G4–Robotic fish
G5–Robotic fish
G6–Robotic fish
G8–Robotic fish
G9–Robotic fish
G14–Robotic fish
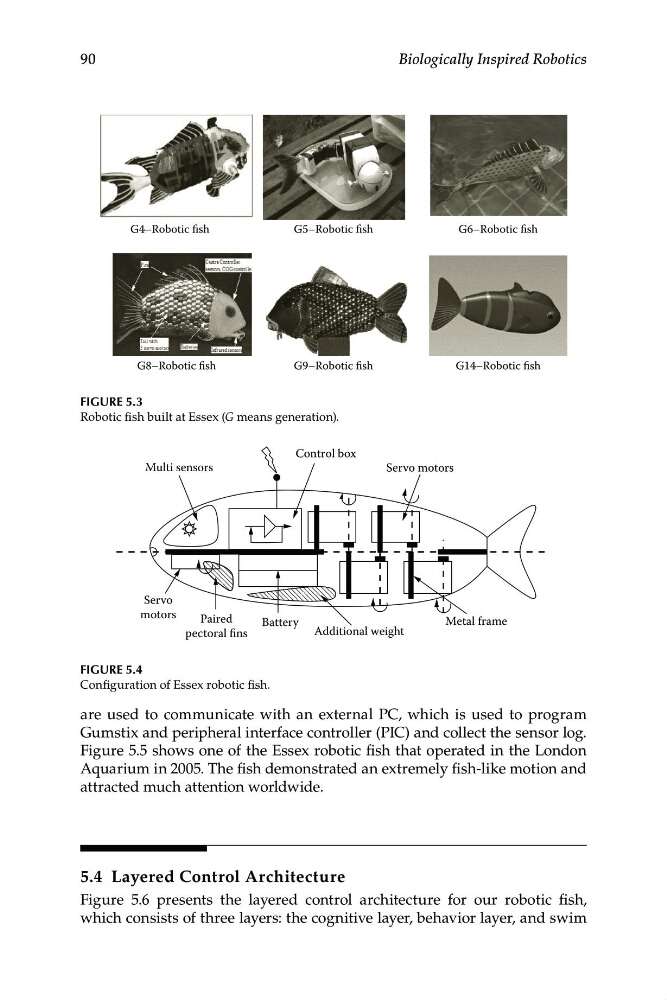
FIGURE 5.3
Robotic fish built at Essex (G means generation).
Multi sensors
Control box
Battery
Additional weight
Metal frame
Paired
pectoral fins
Servo motors
Servo
motors
FIGURE 5.4
Configuration of Essex robotic fish.
are used to communicate with an external PC, which is used to program
Gumstix and peripheral interface controller (PIC) and collect the sensor log.
Figure 5.5 shows one of the Essex robotic fish that operated in the London
Aquarium in 2005. The fish demonstrated an extremely fish-like motion and
attracted much attention worldwide.
5.4 Layered Control Architecture
Figure 5.6 presents the layered control architecture for our robotic fish,
which consists of three layers: the cognitive layer, behavior layer, and swim