

180
K. Mukherjee et al.
td
SOA
∆X
υ2
Dccw
Dcw
Filter
Filter
υ1 Filter
td
SOA
∆X
υ2
Dccw
Dcw
Filter
Filter
υ1 Filter
td
SOA
∆X
υ1
Dccw
Dcw
Filter
Filter
υ2
td
Control
SOA
∆X
Dccw
Dcw
Filter
Filter
td
Control
SOA
∆X
Dccw
Dcw
Filter
Filter
υ1 pass filter
υ2 pass filter
td
Control
SOA
∆X
Dccw
Dcw
Filter
Filter
td
Control
SOA
∆X
Dccw
Dcw
Filter
Filter
υ1 pass filter
υ2 pass filter
B
A
S/D
BS
BS
BS
BS
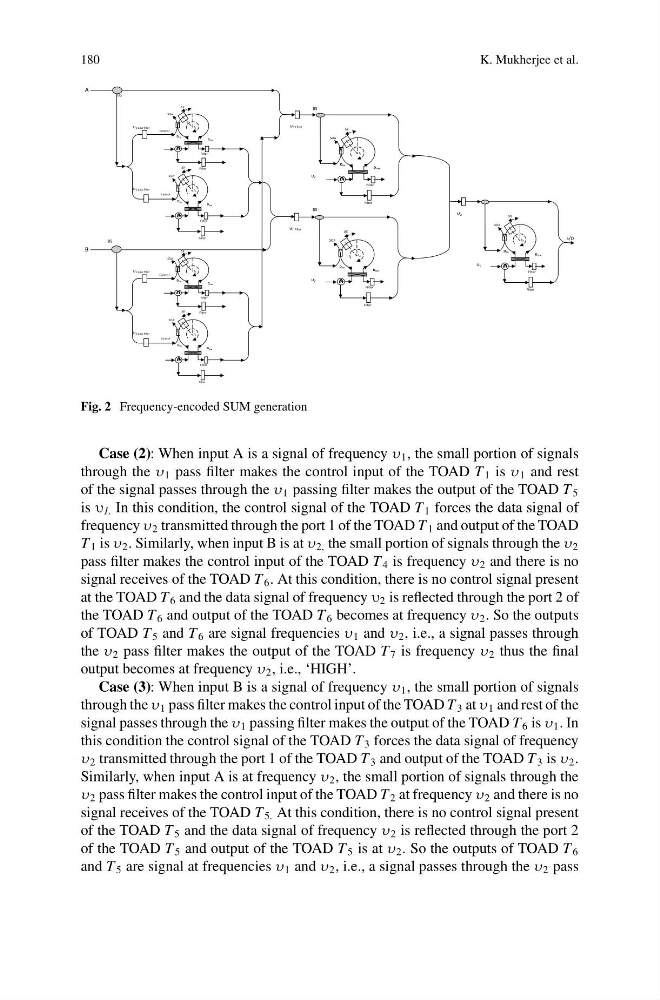
Fig. 2 Frequency-encoded SUM generation
Case (2): When input A is a signal of frequency υ 1 , the small portion of signals
through the υ 1 pass filter makes the control input of the TOAD T 1 is υ 1 and rest
of the signal passes through the υ 1 passing filter makes the output of the TOAD T 5
is υ 1. In this condition, the control signal of the TOAD T 1 forces the data signal of
frequency υ 2 transmitted through the port 1 of the TOAD T 1 and output of the TOAD
T 1 is υ 2 . Similarly, when input B is at υ 2, the small portion of signals through the υ 2
pass filter makes the control input of the TOAD T 4 is frequency υ 2 and there is no
signal receives of the TOAD T 6 . At this condition, there is no control signal present
at the TOAD T 6 and the data signal of frequency υ 2 is reflected through the port 2 of
the TOAD T 6 and output of the TOAD T 6 becomes at frequency υ 2 . So the outputs
of TOAD T 5 and T 6 are signal frequencies υ 1 and υ 2 , i.e., a signal passes through
the υ 2 pass filter makes the output of the TOAD T 7 is frequency υ 2 thus the final
output becomes at frequency υ 2 , i.e., ‘HIGH’.
Case (3): When input B is a signal of frequency υ 1 , the small portion of signals
through the υ 1 pass filter makes the control input of the TOAD T 3 at υ 1 and rest of the
signal passes through the υ 1 passing filter makes the output of the TOAD T 6 is υ 1 . In
this condition the control signal of the TOAD T 3 forces the data signal of frequency
υ 2 transmitted through the port 1 of the TOAD T 3 and output of the TOAD T 3 is υ 2 .
Similarly, when input A is at frequency υ 2 , the small portion of signals through the
υ 2 pass filter makes the control input of the TOAD T 2 at frequency υ 2 and there is no
signal receives of the TOAD T 5. At this condition, there is no control signal present
of the TOAD T 5 and the data signal of frequency υ 2 is reflected through the port 2
of the TOAD T 5 and output of the TOAD T 5 is at υ 2 . So the outputs of TOAD T 6
and T 5 are signal at frequencies υ 1 and υ 2 , i.e., a signal passes through the υ 2 pass