

7 Features of Subsonic Stage of Contact Interaction …
99
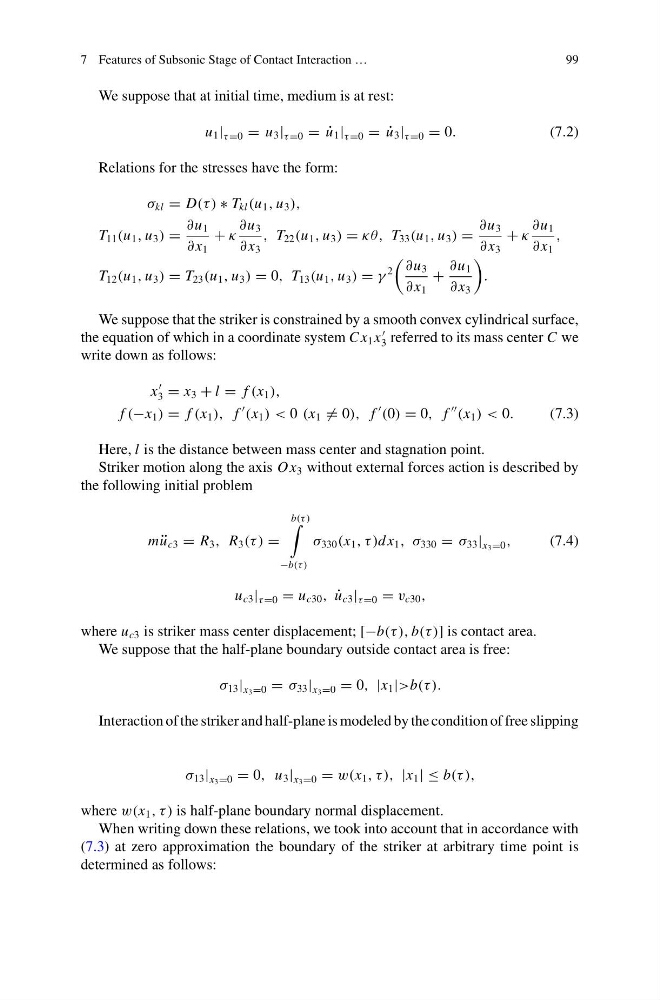
We suppose that at initial time, medium is at rest:
u 1 | τ =0 = u 3 | τ =0 = ˙
u 1 | τ =0 = ˙
u 3 | τ =0 = 0.
(7.2)
Relations for the stresses have the form:
σ kl = D(τ ) ∗ T kl (u 1 , u 3 ),
T 11 (u 1 , u 3 ) =
∂u 1
∂ x 1
+ κ
∂u 3
∂ x 3
, T 22 (u 1 , u 3 ) = κθ, T 33 (u 1 , u 3 ) =
∂u 3
∂ x 3
+ κ
∂u 1
∂ x 1
,
T 12 (u 1 , u 3 ) = T 23 (u 1 , u 3 ) = 0, T 13 (u 1 , u 3 ) = γ
2
∂u 3
∂ x 1
+
∂u 1
∂ x 3
.
We suppose that the striker is constrained by a smooth convex cylindrical surface,
the equation of which in a coordinate system C x 1 x
3 referred to its mass center C we
write down as follows:
x
3 = x 3 + l = f (x 1 ),
f (−x 1 ) = f (x 1 ), f
(x 1 ) < 0 (x 1 = 0), f
(0) = 0, f
(x 1 ) < 0.
(7.3)
Here, l is the distance between mass center and stagnation point.
Striker motion along the axis Ox 3 without external forces action is described by
the following initial problem
m ¨
u c3 = R 3 , R 3 (τ ) =
b(τ )
−b(τ )
σ 330 (x 1 , τ )dx 1 , σ 330 = σ 33 | x 3 =0 ,
(7.4)
u c3 | τ =0 = u c30 , ˙
u c3 | τ =0 = v c30 ,
where u c3 is striker mass center displacement; [−b(τ ), b(τ )] is contact area.
We suppose that the half-plane boundary outside contact area is free:
σ 13 | x 3 =0 = σ 33 | x 3 =0 = 0, |x 1 |>b(τ ).
Interaction of the striker and half-plane is modeled by the condition of free slipping
σ 13 | x 3 =0 = 0, u 3 | x 3 =0 = w(x 1 , τ ), |x 1 | ≤ b(τ ),
where w(x 1 , τ ) is half-plane boundary normal displacement.
When writing down these relations, we took into account that in accordance with
(7.3) at zero approximation the boundary of the striker at arbitrary time point is
determined as follows: