

552
G. Filippi and M. Vasile
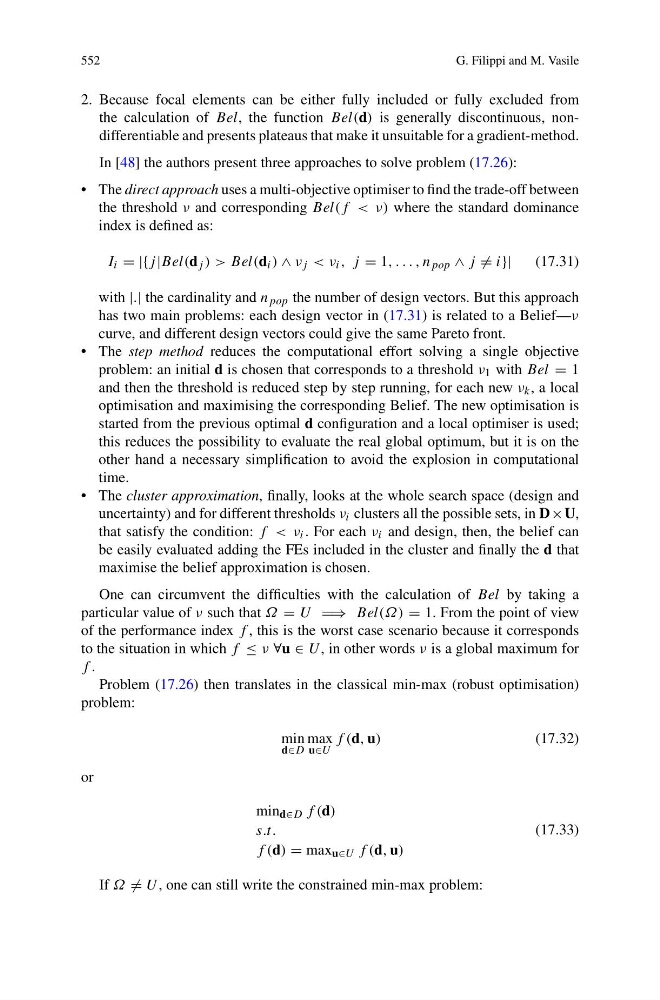
2. Because focal elements can be either fully included or fully excluded from
the calculation of Bel, the function Bel(d) is generally discontinuous, nondifferentiable and presents plateaus that make it unsuitable for a gradient-method.
In [48] the authors present three approaches to solve problem (17.26):
• The direct approach uses a multi-objective optimiser to find the trade-off between
the threshold ν and corresponding Bel(f < ν) where the standard dominance
index is defined as:
I i = |{j |Bel(d j ) > Bel(d i ) ∧ ν j < ν i , j = 1, . . . , n pop ∧ j = i}|
(17.31)
with |.| the cardinality and n pop the number of design vectors. But this approach
has two main problems: each design vector in (17.31) is related to a Belief—ν
curve, and different design vectors could give the same Pareto front.
• The step method reduces the computational effort solving a single objective
problem: an initial d is chosen that corresponds to a threshold ν 1 with Bel = 1
and then the threshold is reduced step by step running, for each new ν k , a local
optimisation and maximising the corresponding Belief. The new optimisation is
started from the previous optimal d configuration and a local optimiser is used;
this reduces the possibility to evaluate the real global optimum, but it is on the
other hand a necessary simplification to avoid the explosion in computational
time.
• The cluster approximation, finally, looks at the whole search space (design and
uncertainty) and for different thresholds ν i clusters all the possible sets, in D×U,
that satisfy the condition: f < ν i . For each ν i and design, then, the belief can
be easily evaluated adding the FEs included in the cluster and finally the d that
maximise the belief approximation is chosen.
One can circumvent the difficulties with the calculation of Bel by taking a
particular value of ν such that Ω = U ⇒ Bel(Ω) = 1. From the point of view
of the performance index f , this is the worst case scenario because it corresponds
to the situation in which f ≤ ν ∀u ∈ U , in other words ν is a global maximum for
f .
Problem (17.26) then translates in the classical min-max (robust optimisation)
problem:
min
d∈D
max
u∈U
f (d, u)
(17.32)
or
min d∈D f (d)
s.t.
f (d) = max u∈U f (d, u)
(17.33)
If Ω = U , one can still write the constrained min-max problem: