

5.4 Space-Time Reference Based on General Relativity
299
5.4 Space-Time Reference Based on General Relativity
Any physical quantity is represented by a set of ordinal numbers, which are usually
associated with the selection of coordinates. In order to study the relationship between
the ordered array and the coordinate transformation in n-dimensional affine space, the
concept of tensor is introduced. The tensor analysis is gradually developed in studies
on differential geometry. In the eighteenth and nineteenth century, Karl F. Gauss,
Georg F. Bernhard Riemann and Edwin B. Christoffel, et al., introduced the concept
of tensor to study the differential geometry. Between 1887 and 1901, a fundamental
framework of tensor analysis was established by Gregorio Ricci-Curbastro and Tullio
Levi-Civita, et al. In 1916, the tensor analysis and Riemann geometry were used by
Albert Einstein to describe the basic principle of general relativity, which greatly
promoted the development of differential geometry. In this way, the tensor analysis
becomes a powerful mathematical tool, used widely.
The XPNAV is carried out in the large-scale space-time frame, and its theoretical
basis is the space-time metric relation of the general relativity. In the studies on the
space-time reference theory and photon arrival-time transformation model for the
XPNAV, some fundamental theories, such as the tensor analysis, Riemann space,
gravity and space-time bending, relativistic timescale, international celestial reference system and its realization, will be involved. Thereby, the related concepts and
basic methods are introduced in this section.
5.4.1 Concept of Riemann Space
5.4.1.1 Tensor Foundation and Metric Tensor
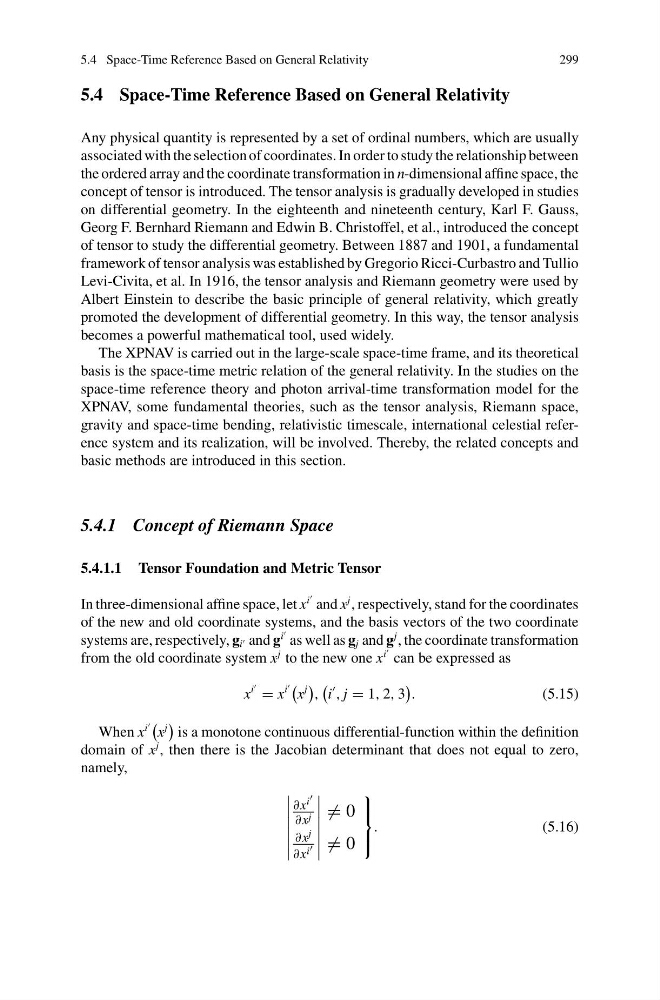
In three-dimensional affine space, let x
i
and x
j , respectively, stand for the coordinates
of the new and old coordinate systems, and the basis vectors of the two coordinate
systems are, respectively, g i and g
i
as well as g j and g
j , the coordinate transformation
from the old coordinate system x
j to the new one x
i
can be expressed as
x
i
= x
i
x
j
,
i
, j = 1, 2, 3
.
(5.15)
When x
i
x
j
is a monotone continuous differential-function within the definition
domain of x
j , then there is the Jacobian determinant that does not equal to zero,
namely,
∂x i
∂x j
= 0
∂x j
∂x i
= 0
⎫
⎪ ⎬
⎪ ⎭
.
(5.16)