

25
Fourier Transform
Now, let us ask ourselves a couple of good questions: “Where can we find linear
systems?” and “Why linear systems are so important for us?” The answer to the
first question is that in nature we almost never encounter a truly linear system! In
other words, almost everything in nature and everything in man-made systems are
nonlinear. In addition, we now know that the nonlinear nature of these systems
makes them so flexible, dynamic, and interesting. Having such an answer for the
first question, the second question becomes more relevant. If there are not many
linear systems in nature, why should we spend a lot of time studying linear systems? The answer is twofold. First, many nonlinear systems, under certain conditions, can be approximated with linear models. This means that if we make sure
that certain conditions are satisfied, instead of dealing with complex and difficult
nonlinear mathematics, we can still use our straightforward linear math. Second,
even in cases where linear models may not be the best approximates of a truly
nonlinear system, considering our lack of knowledge on the type and nature of the
involved nonlinearities, linear models might still be all we can do. For example,
in our model of pushing a cart in crowded parking lot, even though the system is
a nonlinear one, we can still model the system as a linear system if we restrict the
power of the applied push.
Now we get back to the facilities FT provides for analysis of linear systems. In
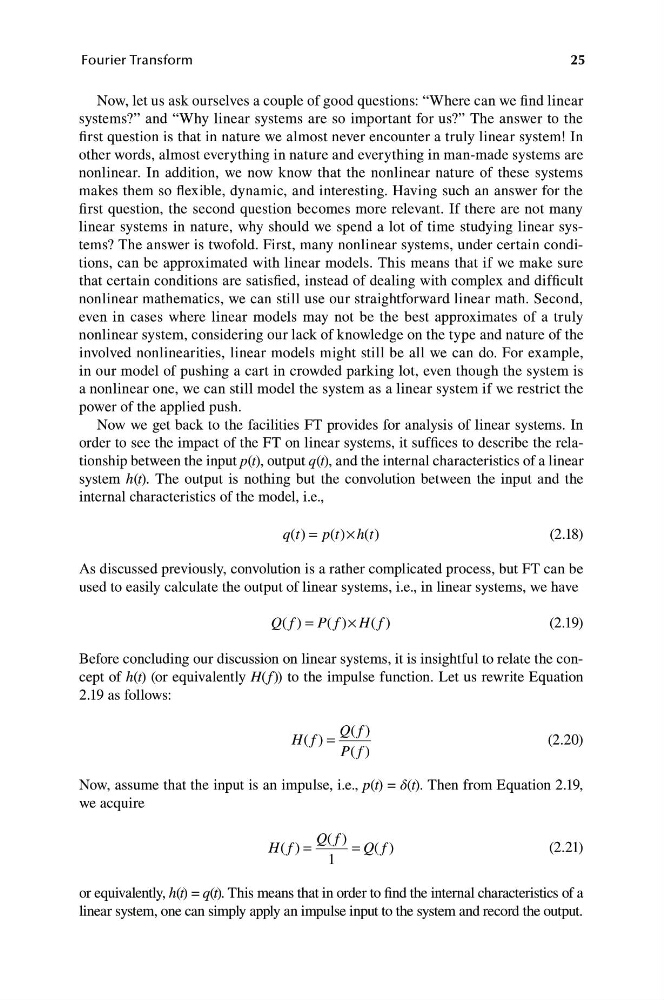
order to see the impact of the FT on linear systems, it suffices to describe the relationship between the input p(t), output q(t), and the internal characteristics of a linear
system h(t). The output is nothing but the convolution between the input and the
internal characteristics of the model, i.e.,
q t
( ) = p t
( )× h( )
t
(2.18)
As discussed previously, convolution is a rather complicated process, but FT can be
used to easily calculate the output of linear systems, i.e., in linear systems, we have
( )
× H f
Q f = P f
( )
( )
(2.19)
Before concluding our discussion on linear systems, it is insightful to relate the concept of h(t) (or equivalently H(f)) to the impulse function. Let us rewrite Equation
2.19 as follows:
Q f
( )
H f
( ) =
(2.20)
P f
( )
Now, assume that the input is an impulse, i.e., p(t) = δ(t). Then from Equation 2.19,
we acquire
Q f
( )
( )
( )
(2.21)
H f =
= Q f
1
or equivalently, h(t) = q(t). This means that in order to find the internal characteristics of a
linear system, one can simply apply an impulse input to the system and record the output.