

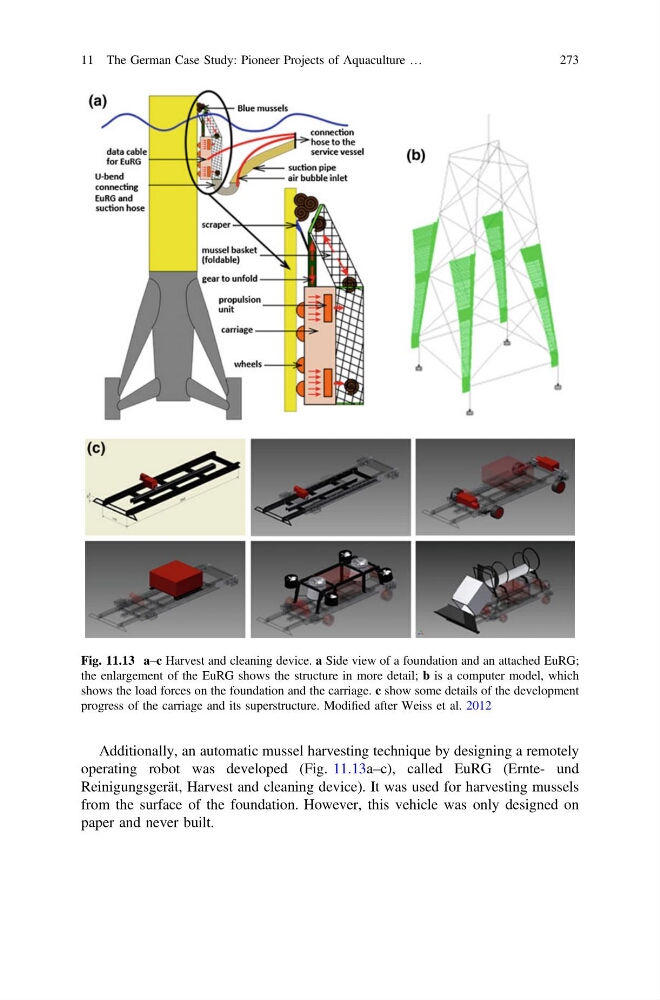
Additionally, an automatic mussel harvesting technique by designing a remotely
operating robot was developed (Fig. 11.13a–c), called EuRG (Ernte- und
Reinigungsgerät, Harvest and cleaning device). It was used for harvesting mussels
from the surface of the foundation. However, this vehicle was only designed on
paper and never built.
Fig. 11.13 a–c Harvest and cleaning device. a Side view of a foundation and an attached EuRG;
the enlargement of the EuRG shows the structure in more detail; b is a computer model, which
shows the load forces on the foundation and the carriage. c show some details of the development
progress of the carriage and its superstructure. Modified after Weiss et al. 2012
11 The German Case Study: Pioneer Projects of Aquaculture …
273