

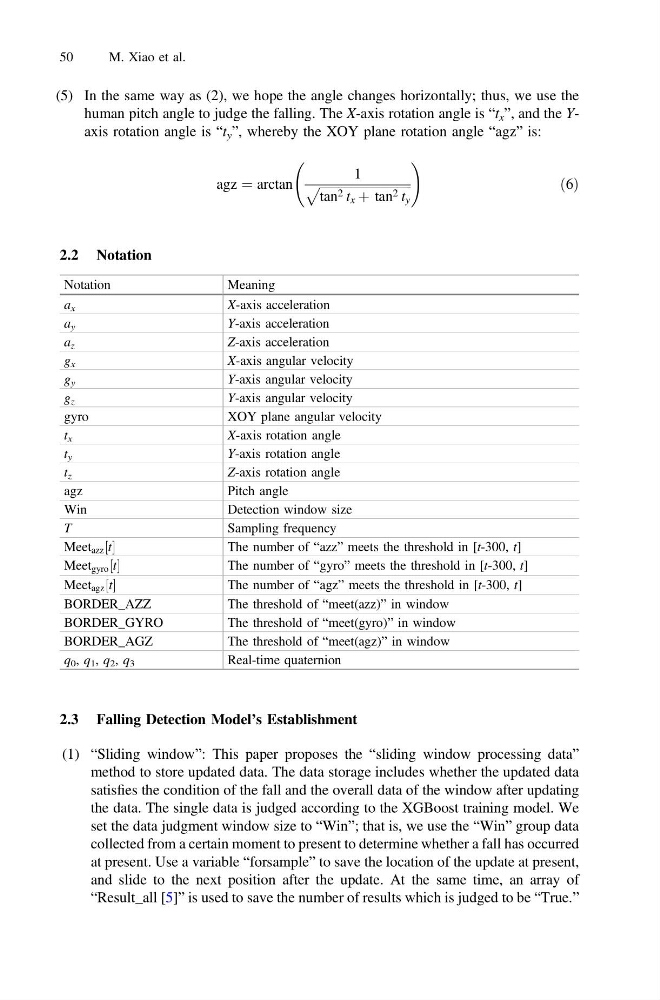
(5) In the same way as (2), we hope the angle changes horizontally; thus, we use the
human pitch angle to judge the falling. The X-axis rotation angle is “t x ”, and the Yaxis rotation angle is “t y ”, whereby the XOY plane rotation angle “agz” is:
agz ¼ arctan
1
ffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffi ffi
tan 2 t x þ tan 2 t y
p
!
ð6Þ
2.2 Notation
Notation
Meaning
a x
X-axis acceleration
a y
Y-axis acceleration
a z
Z-axis acceleration
g x
X-axis angular velocity
g y
Y-axis angular velocity
g z
Y-axis angular velocity
gyro
XOY plane angular velocity
t x
X-axis rotation angle
t y
Y-axis rotation angle
t z
Z-axis rotation angle
agz
Pitch angle
Win
Detection window size
T
Sampling frequency
Meet azz t
½
The number of “azz” meets the threshold in [t-300, t]
Meet gyro t
½
The number of “gyro” meets the threshold in [t-300, t]
Meet agz t
½
The number of “agz” meets the threshold in [t-300, t]
BORDER_AZZ
The threshold of “meet(azz)” in window
BORDER_GYRO
The threshold of “meet(gyro)” in window
BORDER_AGZ
The threshold of “meet(agz)” in window
q 0 , q 1 , q 2 , q 3
Real-time quaternion
2.3 Falling Detection Model’s Establishment
(1) “Sliding window”: This paper proposes the “sliding window processing data”
method to store updated data. The data storage includes whether the updated data
satisfies the condition of the fall and the overall data of the window after updating
the data. The single data is judged according to the XGBoost training model. We
set the data judgment window size to “Win”; that is, we use the “Win” group data
collected from a certain moment to present to determine whether a fall has occurred
at present. Use a variable “forsample” to save the location of the update at present,
and slide to the next position after the update. At the same time, an array of
“Result_all [5]” is used to save the number of results which is judged to be “True.”
50
M. Xiao et al.