

Therefore, without introducing background information, the initial tracking target of
the tracking method is hoped to contain more complete target feature information, such
as more complete edge information and color information, so as to construct a more
perfect target appearance feature to track the target more accurately.
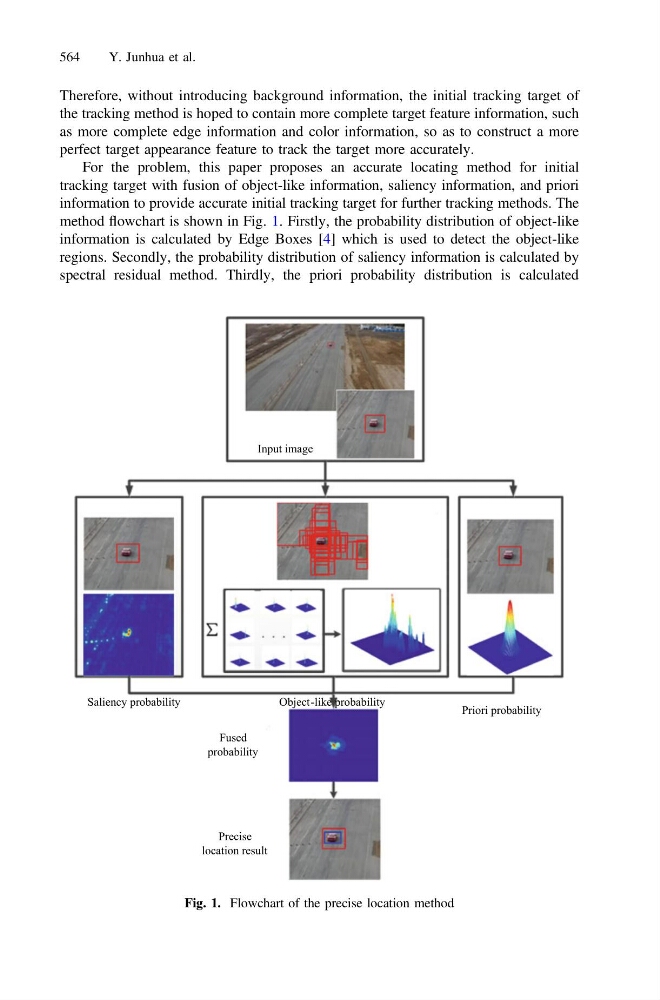
For the problem, this paper proposes an accurate locating method for initial
tracking target with fusion of object-like information, saliency information, and priori
information to provide accurate initial tracking target for further tracking methods. The
method flowchart is shown in Fig. 1. Firstly, the probability distribution of object-like
information is calculated by Edge Boxes [4] which is used to detect the object-like
regions. Secondly, the probability distribution of saliency information is calculated by
spectral residual method. Thirdly, the priori probability distribution is calculated
Input image
Saliency probability
Object-like probability
Priori probability
Fused
probability
Precise
location result
Fig. 1. Flowchart of the precise location method
564
Y. Junhua et al.