

positioning error (Formula 4) and the height positioning error (Formula 5) from the
positioning error vector:
Dd ¼
ffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffiffi ffi
De 2 þ Dn 2
p
ð4Þ
Dh ¼ Du
ð5Þ
Due to the space limit of the paper, only the vertical positioning error of the two
positioning methods is shown in Figs. 4 and 5.
3.2 The Self-correlation of Positioning Error
Because there are some correlations among the slow variable error such as ionospheric
delay error, tropospheric delay error and multipath effect error included in the source of
positioning error, there will be some self-correlation in the positioning error. Before
modeling the positioning error distribution in BDS integrity evaluation, it is necessary
to determine that the error samples approximately meet the requirements of independent and identical distribution. The positioning error of satellite navigation system can
be regarded as a set of time series. The stationarity (approximate independence) of data
can be judged by calculating the self-correlation function of the error sequence with
Reference
receivers
Data
processor
VDB
transmitter
BDS signal
Test
computer
BDS
antenna
VDB
antenna
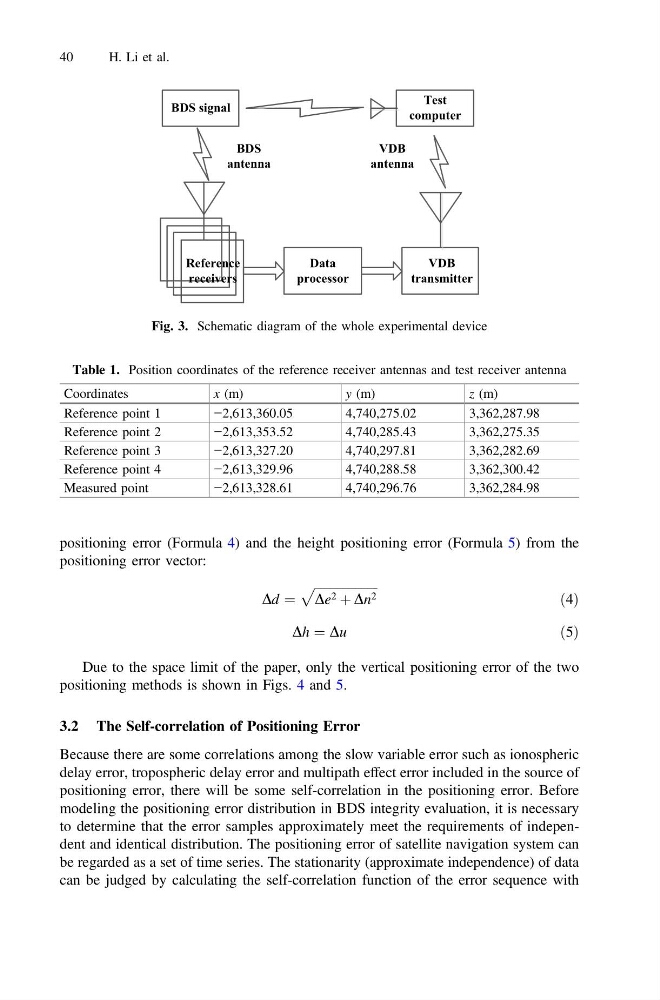
Fig. 3. Schematic diagram of the whole experimental device
Table 1. Position coordinates of the reference receiver antennas and test receiver antenna
Coordinates
x (m)
y (m)
z (m)
Reference point 1
−2,613,360.05
4,740,275.02
3,362,287.98
Reference point 2
−2,613,353.52
4,740,285.43
3,362,275.35
Reference point 3
−2,613,327.20
4,740,297.81
3,362,282.69
Reference point 4
−2,613,329.96
4,740,288.58
3,362,300.42
Measured point
−2,613,328.61
4,740,296.76
3,362,284.98
40
H. Li et al.