

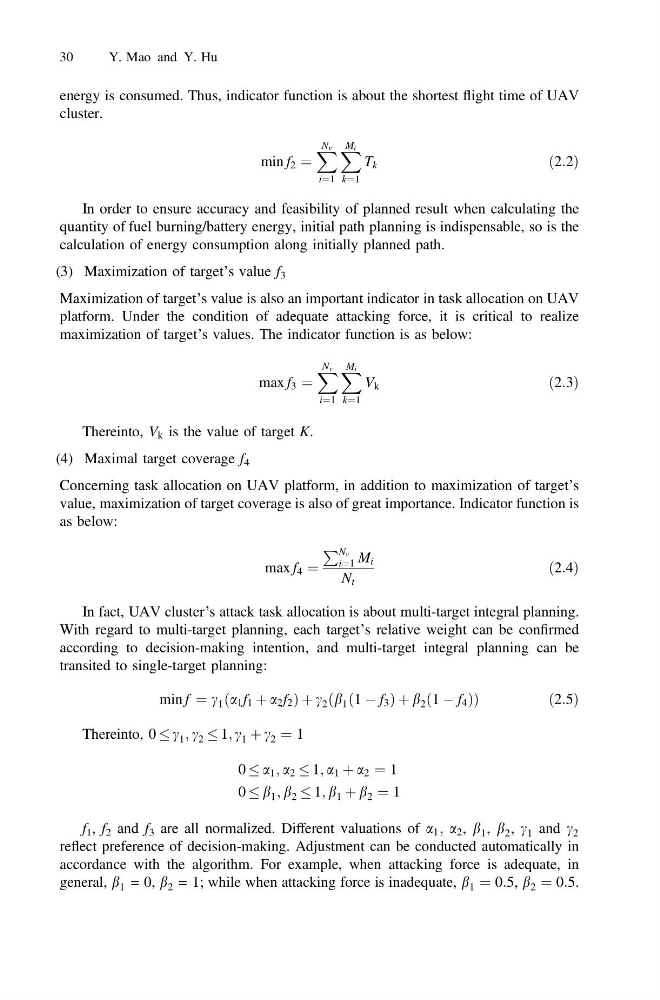
energy is consumed. Thus, indicator function is about the shortest flight time of UAV
cluster.
min f 2 ¼
X N v
i¼1
X M i
k¼1
T k
ð2:2Þ
In order to ensure accuracy and feasibility of planned result when calculating the
quantity of fuel burning/battery energy, initial path planning is indispensable, so is the
calculation of energy consumption along initially planned path.
(3) Maximization of target’s value f 3
Maximization of target’s value is also an important indicator in task allocation on UAV
platform. Under the condition of adequate attacking force, it is critical to realize
maximization of target’s values. The indicator function is as below:
max f 3 ¼
X N v
i¼1
X M i
k¼1
V k
ð2:3Þ
Thereinto, V k is the value of target K.
(4) Maximal target coverage f 4
Concerning task allocation on UAV platform, in addition to maximization of target’s
value, maximization of target coverage is also of great importance. Indicator function is
as below:
max f 4 ¼
P N v
i¼1 M i
N t
ð2:4Þ
In fact, UAV cluster’s attack task allocation is about multi-target integral planning.
With regard to multi-target planning, each target’s relative weight can be confirmed
according to decision-making intention, and multi-target integral planning can be
transited to single-target planning:
min f ¼ c 1 a 1 f 1 þ a 2 f 2
ð
Þþc 2 b 1 1 À f 3
ð
Þþb 2 1 À f 4
ð
Þ
ð
Þ
ð 2:5Þ
Thereinto, 0 c 1 ; c 2 1; c 1 þ c 2 ¼ 1
0 a 1 ; a 2 1; a 1 þ a 2 ¼ 1
0 b 1 ; b 2 1; b 1 þ b 2 ¼ 1
f 1 , f 2 and f 3 are all normalized. Different valuations of a 1 ; a 2 , b 1 , b 2 , c 1 and c 2
reflect preference of decision-making. Adjustment can be conducted automatically in
accordance with the algorithm. For example, when attacking force is adequate, in
general, b 1 = 0, b 2 = 1; while when attacking force is inadequate, b 1 ¼ 0:5, b 2 ¼ 0:5.
30
Y. Mao and Y. Hu