

21.3 The Finite Element Method
245
and with
=
i
C i N i (x),
(21.13b)
Π[ψ] =
i,j
C i C j
N i (x)σ (x)N j (x) −
d
dx
N i (x)
d
dx
N j (x)
dx.
(21.13c)
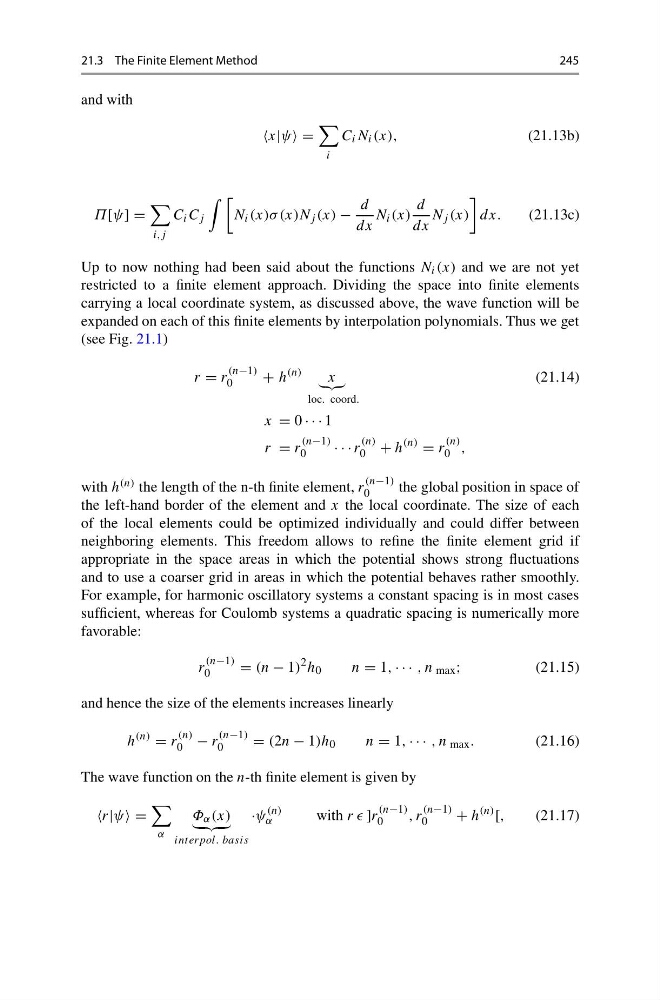
Up to now nothing had been said about the functions N i (x) and we are not yet
restricted to a finite element approach. Dividing the space into finite elements
carrying a local coordinate system, as discussed above, the wave function will be
expanded on each of this finite elements by interpolation polynomials. Thus we get
(see Fig. 21.1)
r = r
(n−1)
0
+ h
(n)
x
loc. coord.
(21.14)
x = 0 · · · 1
r = r
(n−1)
0
· · · r
(n)
0 + h
(n)
= r
(n)
0 ,
with h (n) the length of the n-th finite element, r
(n−1)
0
the global position in space of
the left-hand border of the element and x the local coordinate. The size of each
of the local elements could be optimized individually and could differ between
neighboring elements. This freedom allows to refine the finite element grid if
appropriate in the space areas in which the potential shows strong fluctuations
and to use a coarser grid in areas in which the potential behaves rather smoothly.
For example, for harmonic oscillatory systems a constant spacing is in most cases
sufficient, whereas for Coulomb systems a quadratic spacing is numerically more
favorable:
r
(n−1)
0
= (n − 1)
2 h 0
n = 1, · · · , n max ;
(21.15)
and hence the size of the elements increases linearly
h
(n)
= r
(n)
0 − r
(n−1)
0
= (2n − 1)h 0
n = 1, · · · , n max .
(21.16)
The wave function on the n-th finite element is given by
=
α
Φ α (x)
interpol. basis
·ψ
(n)
α
with r r ]r
(n−1)
0
, r
(n−1)
0
+ h
(n)
[,
(21.17)