

582
9 Variational Principles in Mechanics and Their Applications
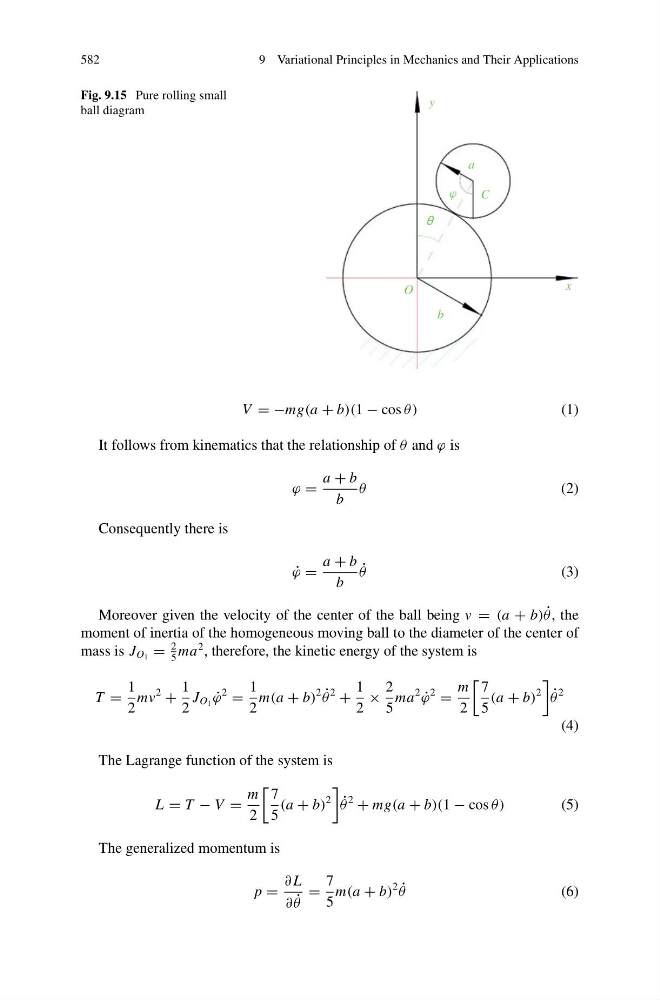
Fig. 9.15 Pure rolling small
ball diagram
O
x
y
a
b
C
ϕ
θ
V = −mg(a + b)(1 − cos θ)
(1)
It follows from kinematics that the relationship of θ and ϕ is
ϕ =
a + b
b
θ
(2)
Consequently there is
˙
ϕ =
a + b
b
˙
θ
(3)
Moreover given the velocity of the center of the ball being v = (a + b) ˙
θ , the
moment of inertia of the homogeneous moving ball to the diameter of the center of
mass is J O 1 =
2
5
ma
2 , therefore, the kinetic energy of the system is
T =
1
2
mv
2
+
1
2
J O 1 ˙
ϕ
2
=
1
2
m(a + b)
2 ˙
θ
2
+
1
2
×
2
5
ma
2
˙
ϕ
2
=
m
2
7
5
(a + b)
2
˙
θ
2
(4)
The Lagrange function of the system is
L = T − V =
m
2
7
5
(a + b)
2
˙
θ
2
+ mg(a + b)(1 − cos θ)
(5)
The generalized momentum is
p =
∂ L
∂ ˙
θ
=
7
5
m(a + b)
2 ˙
θ
(6)