

42
1 Preliminaries
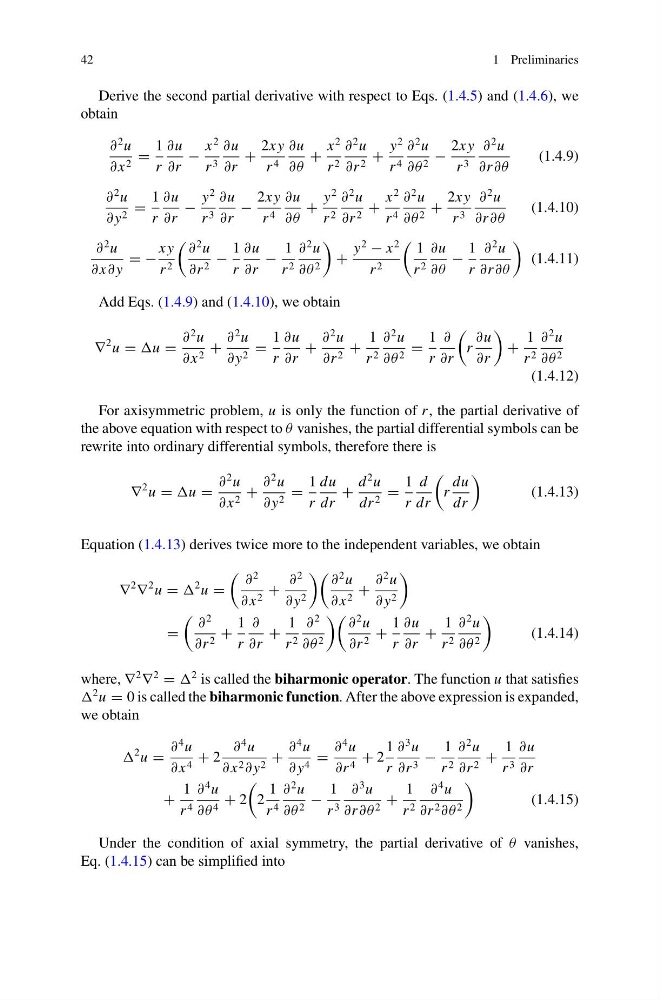
Derive the second partial derivative with respect to Eqs. (1.4.5) and (1.4.6), we
obtain
∂
2 u
∂ x 2 =
1
r
∂u
∂r
−
x
2
r 3
∂u
∂r
+
2x y
r 4
∂u
∂θ
+
x
2
r 2
∂
2 u
∂r 2 +
y
2
r 4
∂
2 u
∂θ 2 −
2x y
r 3
∂
2 u
∂r ∂θ
(1.4.9)
∂
2 u
∂ y 2 =
1
r
∂u
∂r
−
y
2
r 3
∂u
∂r
−
2x y
r 4
∂u
∂θ
+
y
2
r 2
∂
2 u
∂r 2 +
x
2
r 4
∂
2 u
∂θ 2 +
2x y
r 3
∂
2 u
∂r ∂θ
(1.4.10)
∂
2 u
∂ x∂ y
= −
x y
r 2
∂
2 u
∂r 2 −
1
r
∂u
∂r
−
1
r 2
∂
2 u
∂θ 2
+
y
2
− x
2
r 2
1
r 2
∂u
∂θ
−
1
r
∂
2 u
∂r ∂θ
(1.4.11)
Add Eqs. (1.4.9) and (1.4.10), we obtain
∇
2 u = u =
∂
2 u
∂ x 2 +
∂
2 u
∂ y 2 =
1
r
∂u
∂r
+
∂
2 u
∂r 2 +
1
r 2
∂
2 u
∂θ 2 =
1
r
∂
∂r
r
∂u
∂r
+
1
r 2
∂
2 u
∂θ 2
(1.4.12)
For axisymmetric problem, u is only the function of r , the partial derivative of
the above equation with respect to θ vanishes, the partial differential symbols can be
rewrite into ordinary differential symbols, therefore there is
∇
2 u = u =
∂
2 u
∂ x 2 +
∂
2 u
∂ y 2 =
1
r
du
dr
+
d
2 u
dr 2 =
1
r
d
dr
r
du
dr
(1.4.13)
Equation (1.4.13) derives twice more to the independent variables, we obtain
∇
2
∇
2 u =
2 u =
∂
2
∂ x 2 +
∂
2
∂ y 2
∂
2 u
∂ x 2 +
∂
2 u
∂ y 2
=
∂
2
∂r 2 +
1
r
∂
∂r
+
1
r 2
∂
2
∂θ 2
∂
2 u
∂r 2 +
1
r
∂u
∂r
+
1
r 2
∂
2 u
∂θ 2
(1.4.14)
where, ∇
2
∇
2
=
2 is called the biharmonic operator. The function u that satisfies
2 u = 0 is called the biharmonic function. After the above expression is expanded,
we obtain
2 u =
∂
4 u
∂ x 4 + 2
∂
4 u
∂ x 2 ∂ y 2 +
∂
4 u
∂ y 4 =
∂
4 u
∂r 4 + 2
1
r
∂
3 u
∂r 3 −
1
r 2
∂
2 u
∂r 2 +
1
r 3
∂u
∂r
+
1
r 4
∂
4 u
∂θ 4 + 2
2
1
r 4
∂
2 u
∂θ 2 −
1
r 3
∂
3 u
∂r ∂θ 2 +
1
r 2
∂
4 u
∂r 2 ∂θ 2
(1.4.15)
Under the condition of axial symmetry, the partial derivative of θ vanishes,
Eq. (1.4.15) can be simplified into