

560
9 Variational Principles in Mechanics and Their Applications
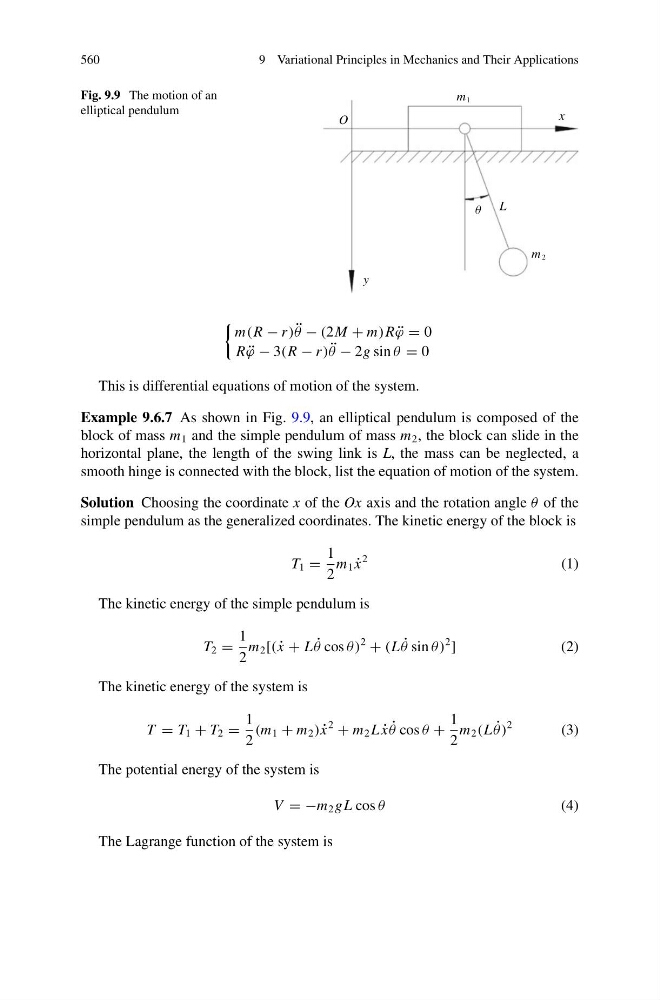
Fig. 9.9 The motion of an
elliptical pendulum
O
x
y
L
m 1
m 2
θ
m(R − r ) ¨
θ − (2M + m)R ¨
ϕ = 0
R ¨
ϕ − 3(R − r ) ¨
θ − 2g sin θ = 0
This is differential equations of motion of the system.
Example 9.6.7 As shown in Fig. 9.9, an elliptical pendulum is composed of the
block of mass m 1 and the simple pendulum of mass m 2 , the block can slide in the
horizontal plane, the length of the swing link is L, the mass can be neglected, a
smooth hinge is connected with the block, list the equation of motion of the system.
Solution Choosing the coordinate x of the Ox axis and the rotation angle θ of the
simple pendulum as the generalized coordinates. The kinetic energy of the block is
T 1 =
1
2
m 1 ˙
x
2
(1)
The kinetic energy of the simple pendulum is
T 2 =
1
2
m 2 [( ˙
x + L ˙
θ cos θ)
2
+ (L ˙
θ sin θ)
2
]
(2)
The kinetic energy of the system is
T = T 1 + T 2 =
1
2
(m 1 + m 2 ) ˙
x
2
+ m 2 L ˙
x ˙
θ cos θ +
1
2
m 2 (L ˙
θ)
2
(3)
The potential energy of the system is
V = −m 2 gL cos θ
(4)
The Lagrange function of the system is