

546
9 Variational Principles in Mechanics and Their Applications
to say, after getting the expression W of work done by the force, generally the virtual
work of the force can not be gotten by the variation of the expression. δ
W is only
the abbreviation of the scalar product
n
i=1
F i · δr i , it is not necessarily the variation
of W .
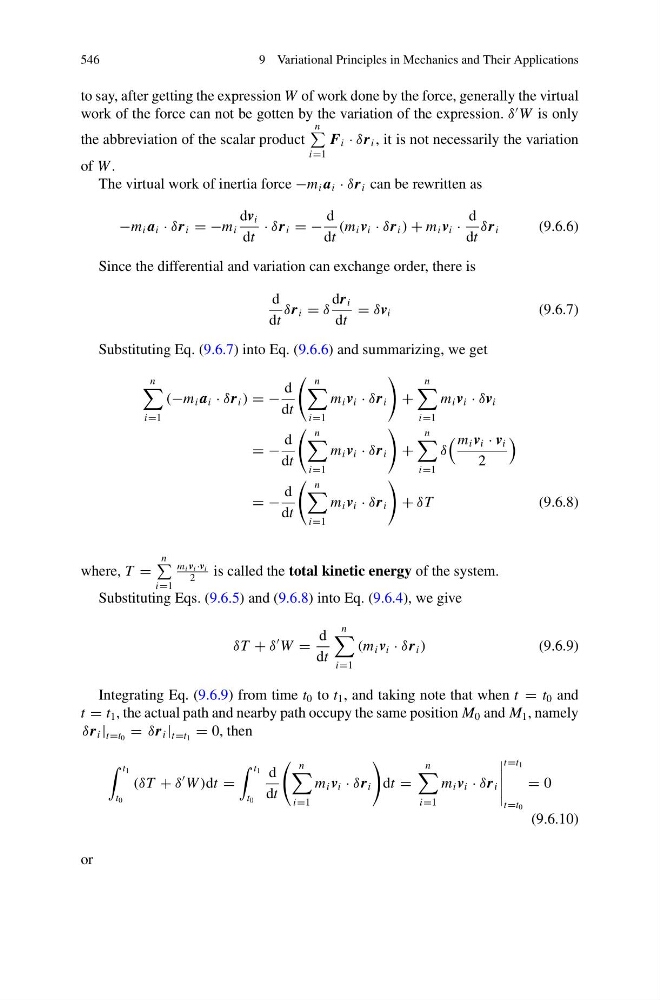
The virtual work of inertia force −m i a i · δr i can be rewritten as
−m i a i · δr i = −m i
dv i
dt
· δr i = −
d
dt
(m i v i · δr i ) + m i v i ·
d
dt
δr i
(9.6.6)
Since the differential and variation can exchange order, there is
d
dt
δr i = δ
dr i
dt
= δv i
(9.6.7)
Substituting Eq. (9.6.7) into Eq. (9.6.6) and summarizing, we get
n
i=1
(−m i a i · δr i ) = −
d
dt
n
i=1
m i v i · δr i
+
n
i=1
m i v i · δv i
= −
d
dt
n
i=1
m i v i · δr i
+
n
i=1
δ
m i v i · v i
2
= −
d
dt
n
i=1
m i v i · δr i
+ δT
(9.6.8)
where, T =
n
i=1
m i v i ·v i
2
is called the total kinetic energy of the system.
Substituting Eqs. (9.6.5) and (9.6.8) into Eq. (9.6.4), we give
δT + δ
W =
d
dt
n
i=1
(m i v i · δr i )
(9.6.9)
Integrating Eq. (9.6.9) from time t 0 to t 1 , and taking note that when t = t 0 and
t = t 1 , the actual path and nearby path occupy the same position M 0 and M 1 , namely
δr i | t=t 0 = δr i | t=t 1 = 0, then
t 1
t 0
(δT + δ
W )dt =
t 1
t 0
d
dt
n
i=1
m i v i · δr i
dt =
n
i=1
m i v i · δr i
t=t 1
t=t 0
= 0
(9.6.10)
or