

528
9 Variational Principles in Mechanics and Their Applications
X i = n j σ i j
(9.2.12)
If the displacement of the elastic body satisfies the continuity condition within the
object namely geometric Eq. (9.1.1) and displacement boundary conditions (9.2.7)
on S u , then it is called the possible displacement or admissible displacement of the
elastic body, it is denoted by u
p
i . The strain corresponding to the possible displacement is called the possible strain or admissible strain, it is denoted by ε
p
i j . According
to the expression (9.1.3), there is
ε
p
i j =
1
2
u
p
i, j + u
p
j,i
(9.2.13)
If the stress of the elastic body satisfies the differential equation of equilibrium
(9.2.3) and the stress boundary conditions (9.2.10) on S σ , then it is called the possible
stress or admissible stress of the elastic body, it is denoted by σ
p
i j . Because the
possible stress state is the stress state in equilibrium with a given volume and surface
forces (or inertial force), it satisfies the differential equation of equilibrium (motion)
and stress boundary conditions, there are
σ
p
i j, j + F i = 0 (or ρu itt ) (in V )
(9.2.14)
X i = X i (on S σ )
(9.2.15)
there
X i = n j σ
p
i j (on S σ )
(9.2.16)
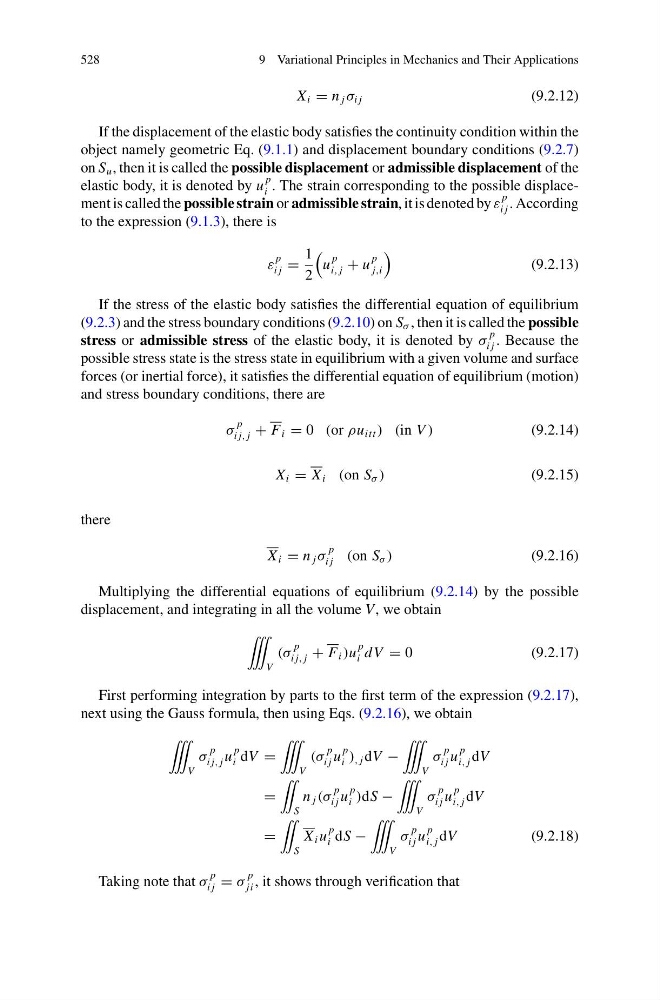
Multiplying the differential equations of equilibrium (9.2.14) by the possible
displacement, and integrating in all the volume V, we obtain
˚
V
(σ
p
i j, j + F i )u
p
i dV = 0
(9.2.17)
First performing integration by parts to the first term of the expression (9.2.17),
next using the Gauss formula, then using Eqs. (9.2.16), we obtain
˚
V
σ
p
i j, j u
p
i dV =
˚
V
(σ
p
i j u
p
i ) , j dV −
˚
V
σ
p
i j u
p
i, j dV
=
¨
S
n j (σ
p
i j u
p
i )dS −
˚
V
σ
p
i j u
p
i, j dV
=
¨
S
X i u
p
i dS −
˚
V
σ
p
i j u
p
i, j dV
(9.2.18)
Taking note that σ
p
i j = σ
p
ji , it shows through verification that