

22
M. Tabatabaei and S. N. Atluri
to 500 µm strut diameter, t = 100 to 500 nm wall thickness, and θ = 60
◦ inclination
angle. The unit cell of micro-architecture was an octahedron without any basal members.
Such architected cellular materials have offered specific mechanical properties (stiffness,
strength, toughness and energy absorption) at low-density regions, which makes them
appropriate for a variety of engineering applications. For example, efforts are under
way to employ the functionality of the cellular metallic/composite materials in energy
absorption [6], mechanical metamaterials [7], bioscaffolds [8], and in adaptive structures
[9].
In the current work, the fiber-reinforced cellular composites recently fabricated
at MIT Media Lab-Center [4] and nickel-based micro-architected cellular materials
recently fabricated at HRL Laboratories [2, 3] are modeled using repetitive Representative Volume Element (RVE) approach consisting of nodes and strut members which
mimic the topology of the cellular material. Each member of the ultralight cellular
metallic/composite materials is considered as single finite three-dimensional (3D) beam
element, and member generalized strains and stresses are calculated under the nonlinear coupling of axial, bidirectional-bending, and torsional deformations. The plastic
hinge method [10, 11] is employed to study the effect of plasticity on the mechanical
response of the micro-architected cellular metal. Using this method, plastic hinge can be
formed along the cellular member everywhere the plasticity condition in terms of generalized stress resultants is satisfied. The effect of nonlinear flexible connections of the
micro-architected cellular composite is studied using the standardized Ramberg-Osgood
function [12] for the moment-rotation relation of flexible connections. The explicit form
of the tangent stiffness matrix is derived utilizing the mixed variational principle [13]
in the co-rotational updated Lagrangian reference frame. Then, we employ the Newton
homotopy algorithm [14] to solve the algebraic equation F(X) = 0, in which X is
the solution vector for the equilibrated nodal generalized coordinates. In contrast to the
Newton-type algorithms which require to invert the Jacobian matrix, homotopy methods
avoid inverting the Jacobian matrix, which makes them simpler to use when the Jacobian
is nearly singular.
The outline of the paper is as follows. The fundamental concepts of the present
methodology are given in Sect. 2. Section 3 is devoted to model micro-architected
cellular metallic materials fabricated at HRL Laboratories [2, 3] and ultralight cellular
composites fabricated at MIT Media Lab-Center [4] using the current methodology
and compare the calculated mechanical properties with the corresponding experimental
measurements. Finally, a conclusion is presented in Sect. 4.
2 Computational Approach
Due to the consideration of the nonlinear coupling of the axial, bidirectional-bending,
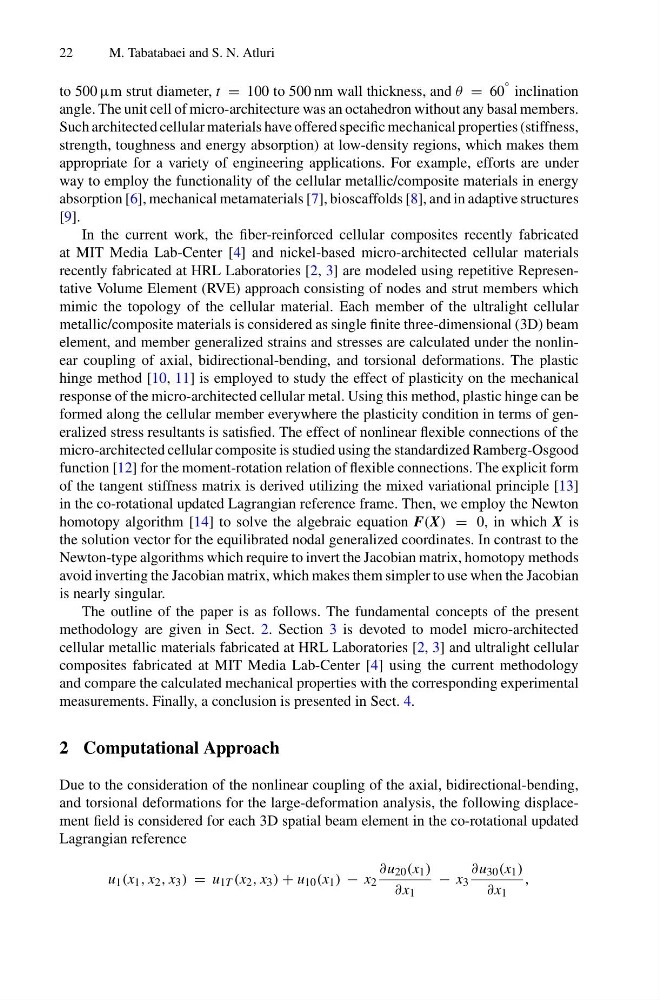
and torsional deformations for the large-deformation analysis, the following displacement field is considered for each 3D spatial beam element in the co-rotational updated
Lagrangian reference
u 1 (x 1 , x 2 , x 3 ) = u 1T (x 2 , x 3 ) + u 10 (x 1 ) − x 2
∂u 20 (x 1 )
∂x 1
− x 3
∂u 30 (x 1 )
∂x 1
,