

3.6 Vibration Isolation and Transmissibility
75
reduction of the transmitted force may be accomplished by adjusting the stiffnesses,
such that η >
√
2.
3.6.1 Transmissibility Due to Support Motions
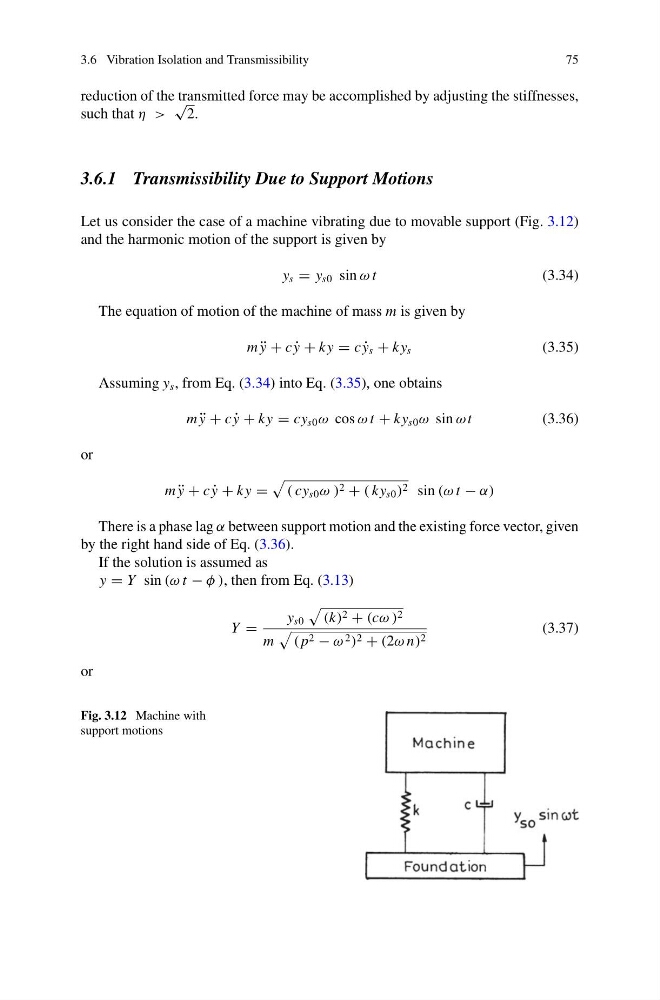
Let us consider the case of a machine vibrating due to movable support (Fig. 3.12)
and the harmonic motion of the support is given by
y s = y s0 sin ω t
(3.34)
The equation of motion of the machine of mass m is given by
m ¨
y + c ˙
y + ky = c ˙
y s + ky s
(3.35)
Assuming y s , from Eq. (3.34) into Eq. (3.35), one obtains
m ¨
y + c ˙
y + ky = cy s0 ω cos ω t + ky s0 ω sin ω t
(3.36)
or
m ¨
y + c ˙
y + ky =
( cy s0 ω ) 2 + ( ky s0 ) 2 sin (ω t − α)
There is a phase lag α between support motion and the existing force vector, given
by the right hand side of Eq. (3.36).
If the solution is assumed as
y = Y sin (ω t − φ ), then from Eq. (3.13)
Y =
y s0
(k) 2 + (cω ) 2
m
( p 2 − ω 2 ) 2 + (2ω n) 2
(3.37)
or
Fig. 3.12 Machine with
support motions