

3.4 Reciprocating Unbalance
71
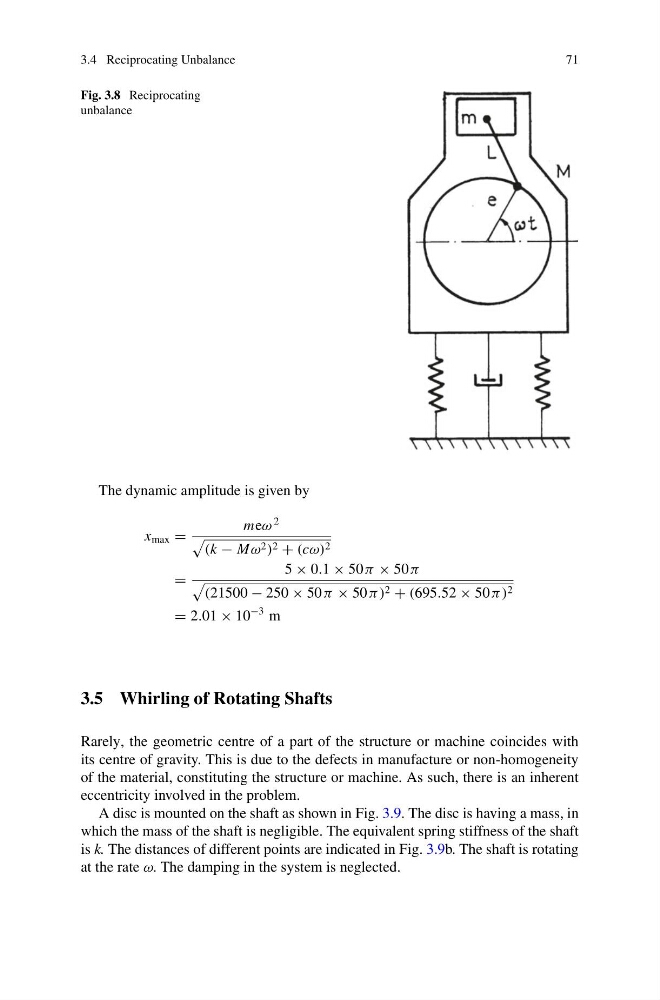
Fig. 3.8 Reciprocating
unbalance
The dynamic amplitude is given by
x max =
meω
2
(k − Mω 2 ) 2 + (cω) 2
=
5 × 0.1 × 50 π × 50 π
(21500 − 250 × 50 π × 50 π) 2 + (695.52 × 50 π) 2
= 2.01 × 10
−3 m
3.5 Whirling of Rotating Shafts
Rarely, the geometric centre of a part of the structure or machine coincides with
its centre of gravity. This is due to the defects in manufacture or non-homogeneity
of the material, constituting the structure or machine. As such, there is an inherent
eccentricity involved in the problem.
A disc is mounted on the shaft as shown in Fig. 3.9. The disc is having a mass, in
which the mass of the shaft is negligible. The equivalent spring stiffness of the shaft
is k. The distances of different points are indicated in Fig. 3.9b. The shaft is rotating
at the rate ω. The damping in the system is neglected.