

13.7 Spline Finite Strip Method of Analysis of Plate Vibration
507
and x = x/b. In concise matrix form,
{ f } = [N ][]{X } e
(13.47)
13.7.3 Strain–Displacement Relationship
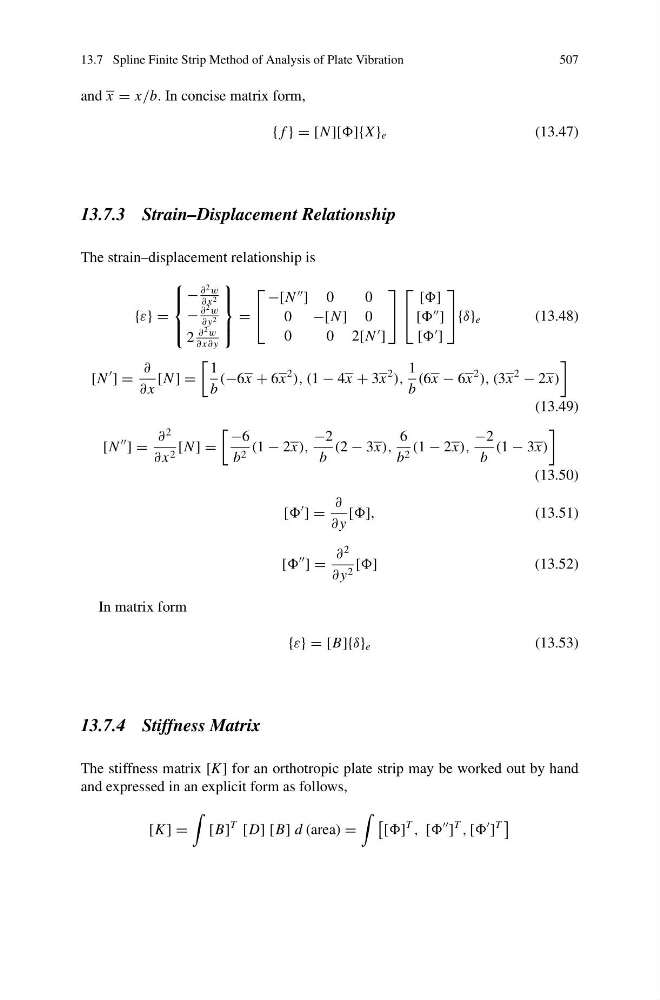
The strain–displacement relationship is
{ε} =
⎧
⎪ ⎨
⎪ ⎩
−
∂
2 w
∂ x 2
−
∂
2 w
∂ y 2
2
∂
2 w
∂ x∂ y
⎫
⎪ ⎬
⎪ ⎭
=
⎡
⎣
−[N
] 0
0
0 −[N ] 0
0
0 2[N
]
⎤
⎦
⎡
⎣
[]
[
]
[
]
⎤
⎦ {δ} e
(13.48)
[N
] =
∂
∂ x
[N ] =
1
b
(−6x + 6x
2
), (1 − 4x + 3x
2
),
1
b
(6x − 6x
2
), (3x
2
− 2x)
(13.49)
[N
] =
∂
2
∂ x 2 [N ] =
−6
b 2 (1 − 2x),
−2
b
(2 − 3x),
6
b 2 (1 − 2x),
−2
b
(1 − 3x)
(13.50)
[
] =
∂
∂ y
[],
(13.51)
[
] =
∂
2
∂ y 2 []
(13.52)
In matrix form
{ε} = [B]{δ} e
(13.53)
13.7.4 Stiffness Matrix
The stiffness matrix [K] for an orthotropic plate strip may be worked out by hand
and expressed in an explicit form as follows,
[K ] =
[B]
T
[D] [B] d (area) =
[]
T
, [
]
T
, [
]
T