

12.7 Flexural Vibration of Plates
467
or
f = [ 1 x y x
2 x y y
2 x
3 x
2 y xy
2 y
3 x
3 y xy
3
]
⎧
⎪ ⎪ ⎪ ⎨
⎪ ⎪ ⎪ ⎩
α 1
α 2
. . .
α 12
⎫
⎪ ⎪ ⎪ ⎬
⎪ ⎪ ⎪ ⎭
(12.120)
or
{ f } = [C] {α}
(12.121)
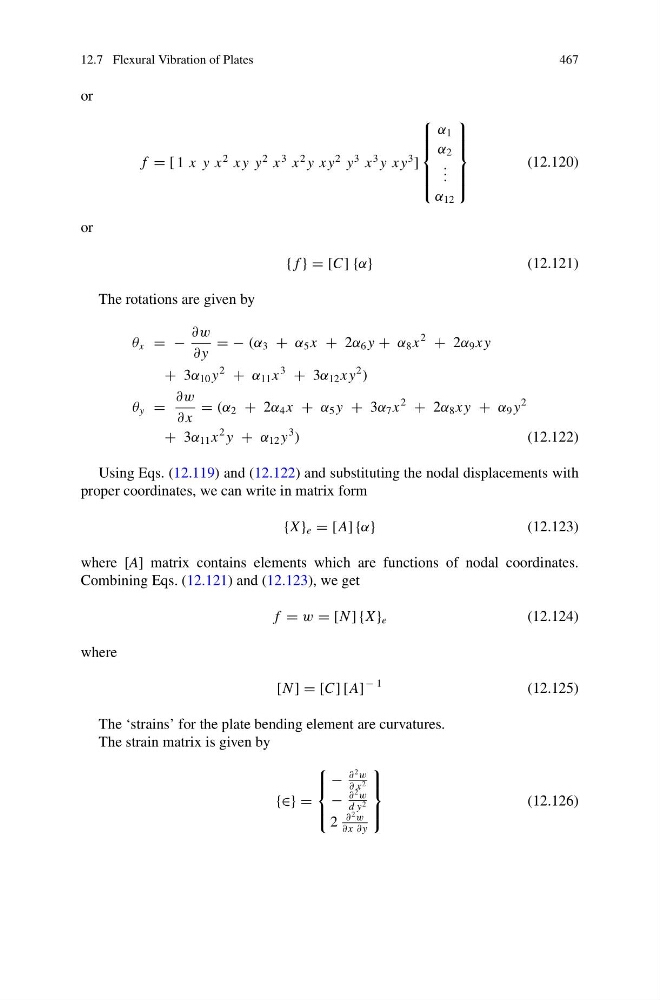
The rotations are given by
θ x = −
∂w
∂ y
= − (α 3 + α 5 x + 2α 6 y + α 8 x
2
+ 2α 9 x y
+ 3α 10 y
2
+ α 11 x
3
+ 3α 12 x y
2
)
θ y =
∂w
∂ x
= (α 2 + 2α 4 x + α 5 y + 3α 7 x
2
+ 2α 8 x y + α 9 y
2
+ 3α 11 x
2 y + α 12 y
3
)
(12.122)
Using Eqs. (12.119) and (12.122) and substituting the nodal displacements with
proper coordinates, we can write in matrix form
{X } e = [A] {α}
(12.123)
where [A] matrix contains elements which are functions of nodal coordinates.
Combining Eqs. (12.121) and (12.123), we get
f = w = [N ] {X } e
(12.124)
where
[N ] = [C] [A]
− 1
(12.125)
The ‘strains’ for the plate bending element are curvatures.
The strain matrix is given by
{∈} =
⎧
⎪ ⎨
⎪ ⎩
−
∂
2 w
∂ x 2
−
∂
2 w
d y 2
2
∂
2 w
∂ x ∂ y
⎫
⎪ ⎬
⎪ ⎭
(12.126)