

12.5 Vibration of Timoshenko Beams
457
The shear force and bending moment is related as follows:
∂ M
∂ x
= V
(12.64)
Equation (12.64) means that the rotary inertia term is ignored in the moment equilibrium equation within the element, but the effect of rotary inertia will nevertheless
be included in lumped form at the nodes.
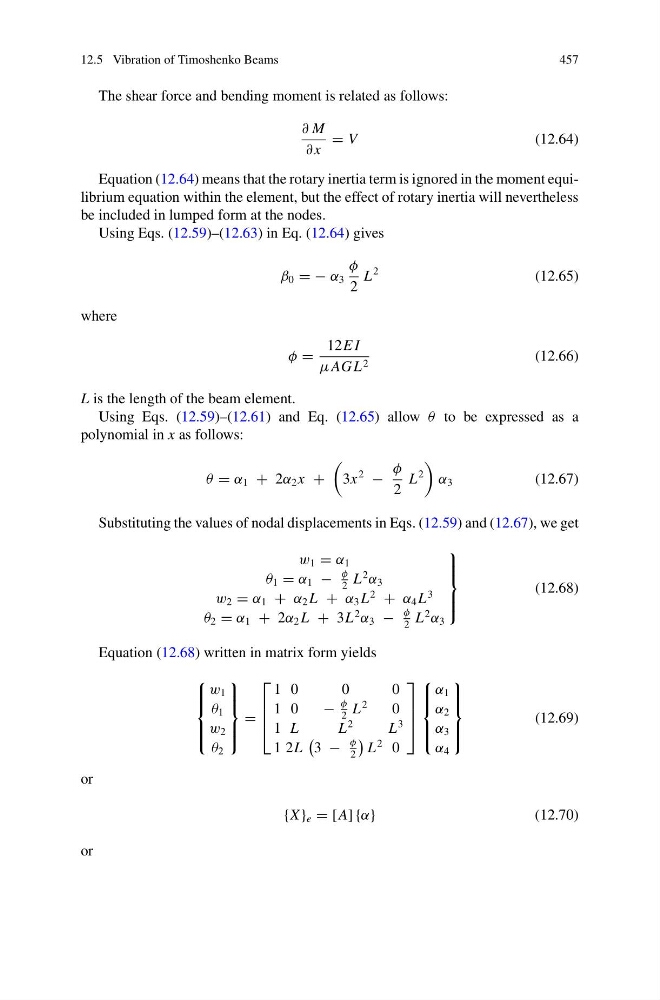
Using Eqs. (12.59)–(12.63) in Eq. (12.64) gives
β 0 = − α 3
φ
2
L
2
(12.65)
where
φ =
12E I
μAG L 2
(12.66)
L is the length of the beam element.
Using Eqs. (12.59)–(12.61) and Eq. (12.65) allow θ to be expressed as a
polynomial in x as follows:
θ = α 1 + 2α 2 x +
3x
2
−
φ
2
L
2
α 3
(12.67)
Substituting the values of nodal displacements in Eqs. (12.59) and (12.67), we get
w 1 = α 1
θ 1 = α 1 −
φ
2
L
2
α 3
w 2 = α 1 + α 2 L + α 3 L
2
+ α 4 L
3
θ 2 = α 1 + 2α 2 L + 3L
2
α 3 −
φ
2
L
2
α 3
⎫
⎪ ⎪ ⎬
⎪ ⎪ ⎭
(12.68)
Equation (12.68) written in matrix form yields
⎧
⎪ ⎪ ⎨
⎪ ⎪ ⎩
w 1
θ 1
w 2
θ 2
⎫
⎪ ⎪ ⎬
⎪ ⎪ ⎭
=
⎡
⎢
⎢
⎣
1 0
0
0
1 0
−
φ
2
L
2
0
1 L
L
2
L
3
1 2L
3 −
φ
2
L
2 0
⎤
⎥
⎥
⎦
⎧
⎪ ⎪ ⎨
⎪ ⎪ ⎩
α 1
α 2
α 3
α 4
⎫
⎪ ⎪ ⎬
⎪ ⎪ ⎭
(12.69)
or
{X } e = [A] {α}
(12.70)
or