

10.8 Beam Segments with Distributed Mass Having Shear Deformation…
423
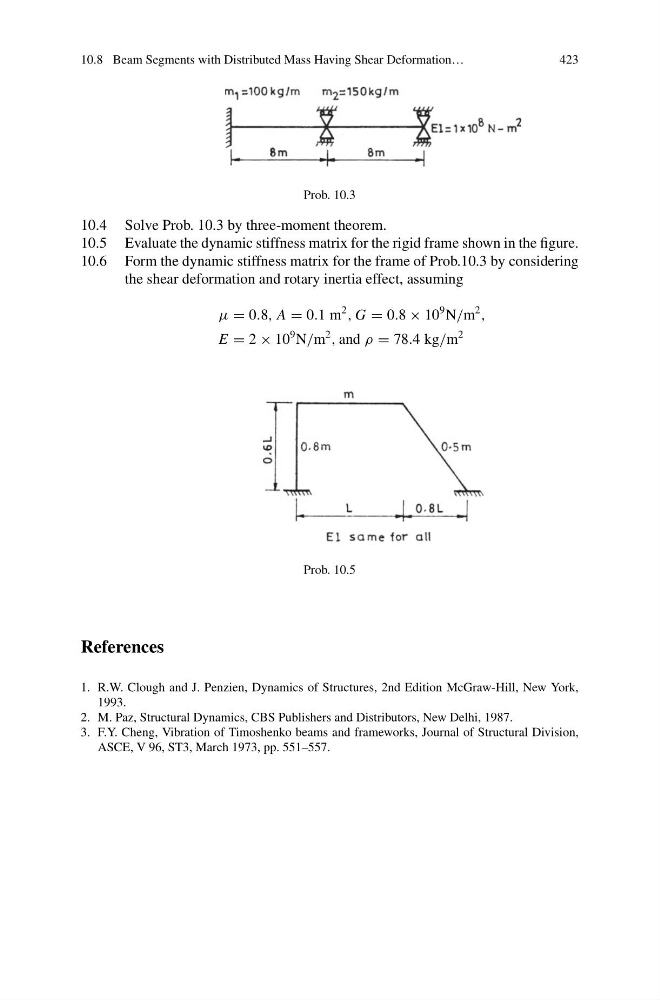
Prob. 10.3
10.4 Solve Prob. 10.3 by three-moment theorem.
10.5 Evaluate the dynamic stiffness matrix for the rigid frame shown in the figure.
10.6 Form the dynamic stiffness matrix for the frame of Prob.10.3 by considering
the shear deformation and rotary inertia effect, assuming
μ = 0.8, A = 0.1 m
2
, G = 0.8 × 10
9 N/m
2
,
E = 2 × 10
9 N/m
2
, and ρ = 78.4 kg/m
2
Prob. 10.5
References
1. R.W. Clough and J. Penzien, Dynamics of Structures, 2nd Edition McGraw-Hill, New York,
1993.
2. M. Paz, Structural Dynamics, CBS Publishers and Distributors, New Delhi, 1987.
3. F.Y. Cheng, Vibration of Timoshenko beams and frameworks, Journal of Structural Division,
ASCE, V 96, ST3, March 1973, pp. 551–557.