

422
10 Dynamic Direct Stiffness Method
SMY 1 =
−1
α 2 + β 2
D
α
2
+ s
2
β
2
− s
2
s
2
− r
2
−
s
2
r
2
+ s
2
+ 2β
2
α
2
βα
sin bα
sin bβ
E I
L 2 +
α
2
+ s
2
β
2
− s
2
α 2 + β 2
D
r
2
− s
2
cos bα
cos bβ
E I
L 2
(10.117)
SMY 2 =
α
2
+ s
2
β
2
− α
2
D
cos bβ − cos bα
E I
L 2
(10.118)
SV Y 1 =
1
bD
α
2
+ s
2
α
sin bα
+
β
2
− s
2
β
sin bβ
E I
L 3
(10.119)
SV Y 2 =
1
bD
α
2
+ s
2
α
cos bβ sin bα
+
β
2
− s
2
β
sin bβ cos bα
E I
L 3 (10.120)
D =
2
α
2
+ s
2
β
2
− s
2
b 2
α 2 + β 2
1 − cos bβ cos bα
+
β
2
α
2
+ s
2
2 + α
2
β
2
− s
2
2
α βb 2
α 2 + β 2
sin bβ sin bα
(10.121)
Exercise 10
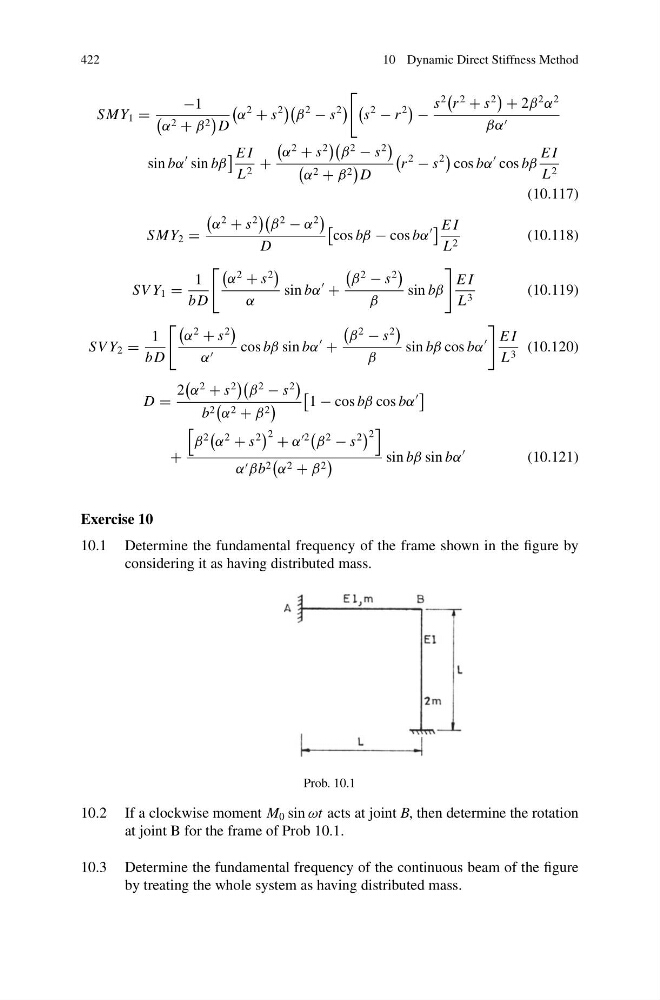
10.1 Determine the fundamental frequency of the frame shown in the figure by
considering it as having distributed mass.
Prob. 10.1
10.2 If a clockwise moment M 0 sin ωt acts at joint B, then determine the rotation
at joint B for the frame of Prob 10.1.
10.3 Determine the fundamental frequency of the continuous beam of the figure
by treating the whole system as having distributed mass.