

418
10 Dynamic Direct Stiffness Method
b
2
=
1
E I
ρ AL
4 p
2
(10.84)
r
2
=
I
AL 2
(10.85)
s
2
=
E I
ρ AG L 2
(10.86)
ξ =
x
L
(10.87)
C
1 =
b
L
α
2
+ s
2
α
C 1 = T C 1
(10.88)
C
2 =
b
L
α
2
+ s
2
α
C 2 = T C 2
(10.89)
C
3 = −
b
L
β
2
− s
2
β
C 3 = −U
C 3
(10.90)
and
C
4 =
b
L
β
2
− s
2
β
C 4 = −U
C 4
(10.91)
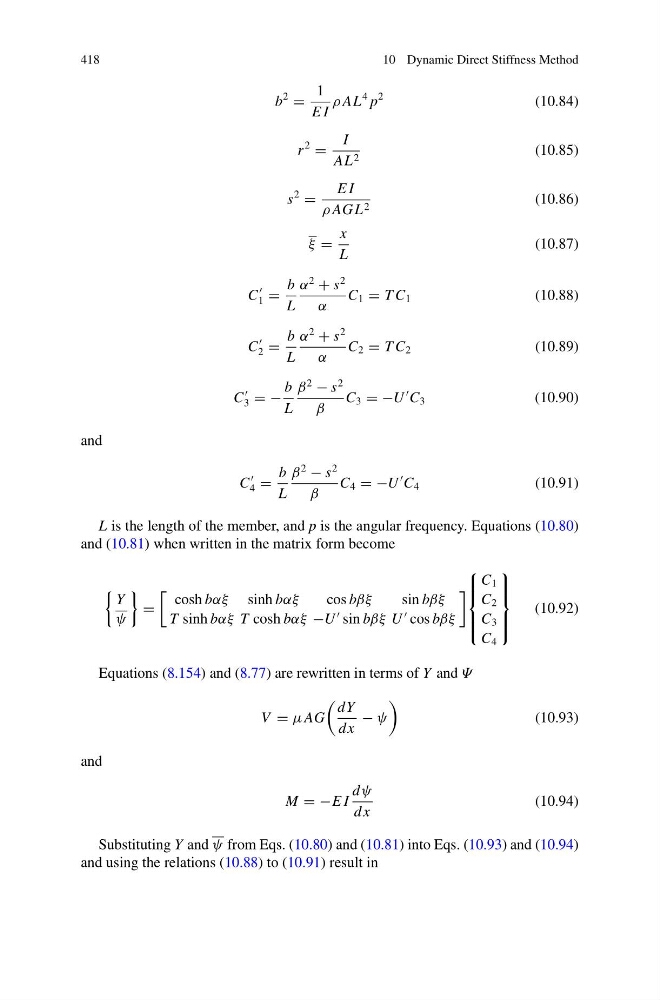
L is the length of the member, and p is the angular frequency. Equations (10.80)
and (10.81) when written in the matrix form become
Y
ψ
=
cosh bαξ sinh bαξ
cos bβξ
sin bβξ
T sinh bαξ T cosh bαξ −U
sin bβξ U
cos bβξ
⎧
⎪ ⎪ ⎨
⎪ ⎪ ⎩
C 1
C 2
C 3
C 4
⎫
⎪ ⎪ ⎬
⎪ ⎪ ⎭
(10.92)
Equations (8.154) and (8.77) are rewritten in terms of Y and Ψ
V = μAG
dY
dx
− ψ
(10.93)
and
M = −E I
dψ
dx
(10.94)
Substituting Y and ψ from Eqs. (10.80) and (10.81) into Eqs. (10.93) and (10.94)
and using the relations (10.88) to (10.91) result in