

410
10 Dynamic Direct Stiffness Method
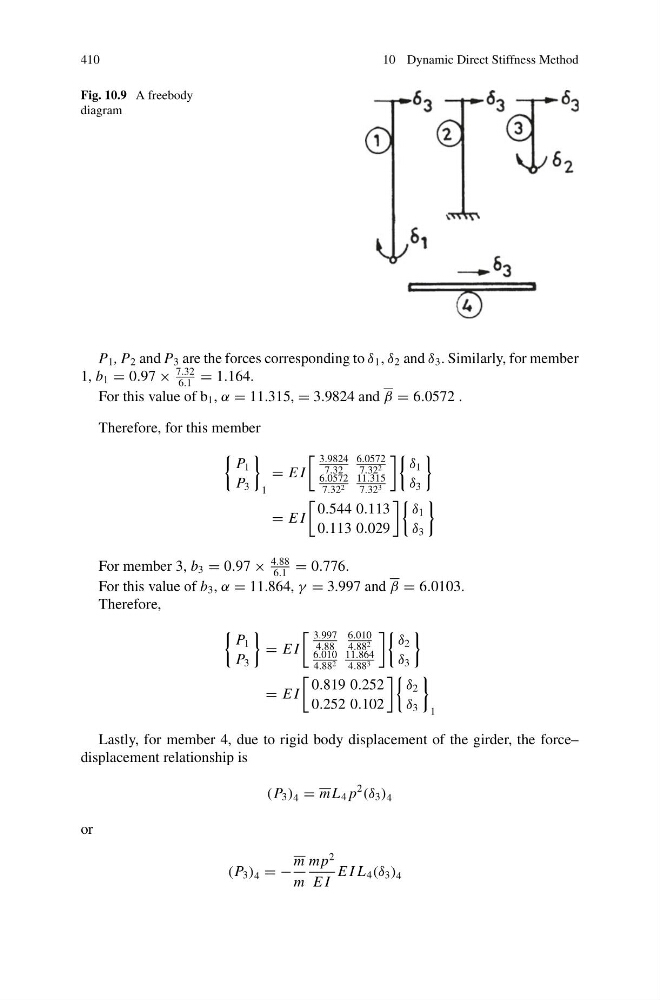
Fig. 10.9 A freebody
diagram
P 1 , P 2 and P 3 are the forces corresponding to δ 1 , δ 2 and δ 3 . Similarly, for member
1, b 1 = 0.97 ×
7.32
6.1
= 1.164.
For this value of b 1 , α = 11.315, = 3.9824 and β = 6.0572 .
Therefore, for this member
P 1
P 3
1
= E I
3.9824
7.32
6.0572
7.32 2
6.0572
7.32 2
11.315
7.32 3
δ 1
δ 3
= E I
0.544 0.113
0.113 0.029
δ 1
δ 3
For member 3, b 3 = 0.97 ×
4.88
6.1
= 0.776.
For this value of b 3 , α = 11.864, γ = 3.997 and β = 6.0103.
Therefore,
P 1
P 3
= E I
3.997
4.88
6.010
4.88 2
6.010
4.88 2
11.864
4.88 3
δ 2
δ 3
= E I
0.819 0.252
0.252 0.102
δ 2
δ 3
1
Lastly, for member 4, due to rigid body displacement of the girder, the force–
displacement relationship is
(P 3 ) 4 = m L 4 p
2
(δ 3 ) 4
or
(P 3 ) 4 = −
m
m
mp
2
E I
E I L 4 (δ 3 ) 4