

10.4 Dynamic Stiffness Matrix in Bending
405
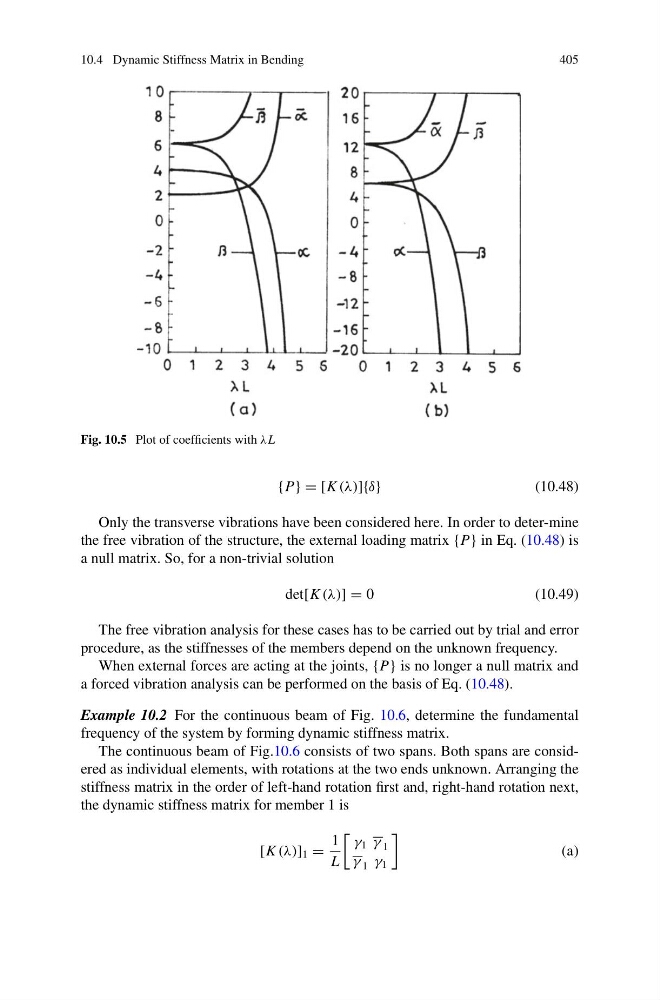
Fig. 10.5 Plot of coefficients with λL
{P} = [K (λ)]{δ}
(10.48)
Only the transverse vibrations have been considered here. In order to deter-mine
the free vibration of the structure, the external loading matrix {P} in Eq. (10.48) is
a null matrix. So, for a non-trivial solution
det[K (λ)] = 0
(10.49)
The free vibration analysis for these cases has to be carried out by trial and error
procedure, as the stiffnesses of the members depend on the unknown frequency.
When external forces are acting at the joints, {P} is no longer a null matrix and
a forced vibration analysis can be performed on the basis of Eq. (10.48).
Example 10.2 For the continuous beam of Fig. 10.6, determine the fundamental
frequency of the system by forming dynamic stiffness matrix.
The continuous beam of Fig.10.6 consists of two spans. Both spans are considered as individual elements, with rotations at the two ends unknown. Arranging the
stiffness matrix in the order of left-hand rotation first and, right-hand rotation next,
the dynamic stiffness matrix for member 1 is
[K (λ)] 1 =
1
L
γ 1 γ 1
γ 1 γ 1
(a)