

300
7 Forced Vibration Analysis of Multiple Degrees of Freedom System
x r (t) =
n
r =1
φ
(r )
i ξ r
(7.102)
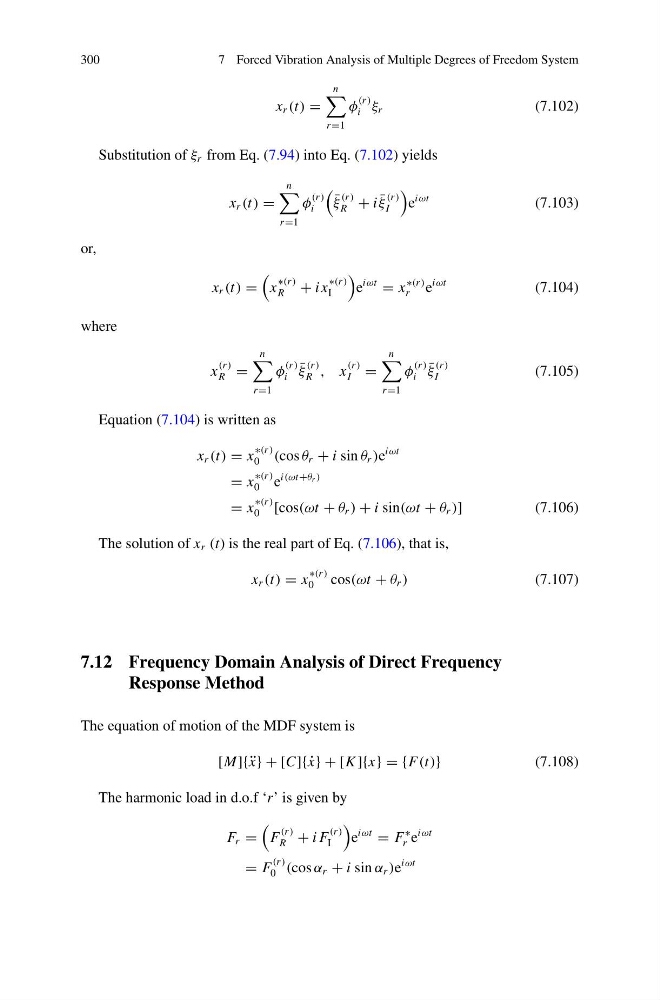
Substitution of ξ r from Eq. (7.94) into Eq. (7.102) yields
x r (t) =
n
r =1
φ
(r )
i
¯
ξ
(r )
R + i ¯
ξ
(r )
I
e
iωt
(7.103)
or,
x r (t) =
x
∗(r )
R
+ i x
∗(r )
I
e
iωt
= x
∗(r )
r
e
iωt
(7.104)
where
x
(r )
R =
n
r =1
φ
(r )
i
¯
ξ
(r )
R , x
(r )
I =
n
r =1
φ
(r )
i
¯
ξ
(r )
I
(7.105)
Equation (7.104) is written as
x r (t) = x
∗(r )
0 (cos θ r + i sin θ r )e
iωt
= x
∗(r )
0 e
i(ωt+θ r )
= x
∗(r )
0 [cos(ωt + θ r ) + i sin(ωt + θ r )]
(7.106)
The solution of x r (t) is the real part of Eq. (7.106), that is,
x r (t) = x
∗(r )
0
cos(ωt + θ r )
(7.107)
7.12 Frequency Domain Analysis of Direct Frequency
Response Method
The equation of motion of the MDF system is
[M]{ ¨
x} + [C]{ ˙
x} + [K ]{x} = {F(t)}
(7.108)
The harmonic load in d.o.f ‘r’ is given by
F r =
F
(r )
R + i F
(r )
I
e
iωt
= F
∗
r e
iωt
= F
(r )
0 (cos α r + i sin α r )e
iωt