

6.15 Rayleigh–Ritz Method
231
6.15 Rayleigh–Ritz Method
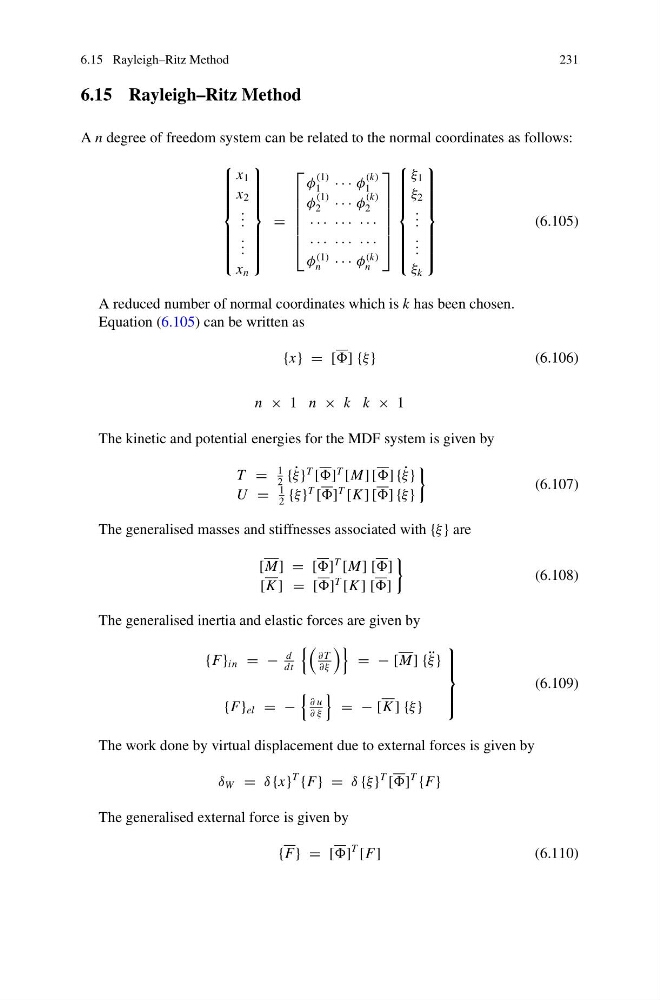
A n degree of freedom system can be related to the normal coordinates as follows:
⎧
⎪ ⎪ ⎪ ⎪ ⎪ ⎪ ⎨
⎪ ⎪ ⎪ ⎪ ⎪ ⎪ ⎩
x 1
x 2
. . .
. . .
x n
⎫
⎪ ⎪ ⎪ ⎪ ⎪ ⎪ ⎬
⎪ ⎪ ⎪ ⎪ ⎪ ⎪ ⎭
=
⎡
⎢
⎢
⎢
⎢
⎢
⎣
φ
(1)
1 · · · φ
(k)
1
φ
(1)
2 · · · φ
(k)
2
· · · · · · · · ·
· · · · · · · · ·
φ
(1)
n · · · φ
(k)
n
⎤
⎥
⎥
⎥
⎥
⎥
⎦
⎧
⎪ ⎪ ⎪ ⎪ ⎪ ⎪ ⎨
⎪ ⎪ ⎪ ⎪ ⎪ ⎪ ⎩
ξ 1
ξ 2
. . .
. . .
ξ k
⎫
⎪ ⎪ ⎪ ⎪ ⎪ ⎪ ⎬
⎪ ⎪ ⎪ ⎪ ⎪ ⎪ ⎭
(6.105)
A reduced number of normal coordinates which is k has been chosen.
Equation (6.105) can be written as
{x} = [] {ξ }
(6.106)
n × 1 n × k k × 1
The kinetic and potential energies for the MDF system is given by
T =
1
2
{ ˙
ξ }
T
[]
T
[M] [] { ˙
ξ }
U =
1
2
{ξ }
T
[]
T
[K ] [] {ξ }
(6.107)
The generalised masses and stiffnesses associated with {ξ } are
[M] = []
T
[M] []
[K ] = []
T
[K ] []
(6.108)
The generalised inertia and elastic forces are given by
{F} in = −
d
dt
∂ T
∂ξ
= − [M] { ¨
ξ }
{F} el = −
∂ u
∂ ξ
= − [K ] {ξ }
⎫
⎪ ⎪ ⎬
⎪ ⎪ ⎭
(6.109)
The work done by virtual displacement due to external forces is given by
δ W = δ {x}
T
{F} = δ {ξ }
T
[]
T
{F}
The generalised external force is given by
{F} = []
T
[F]
(6.110)