

184
6 Free Vibration of Multiple Degrees of Freedom System
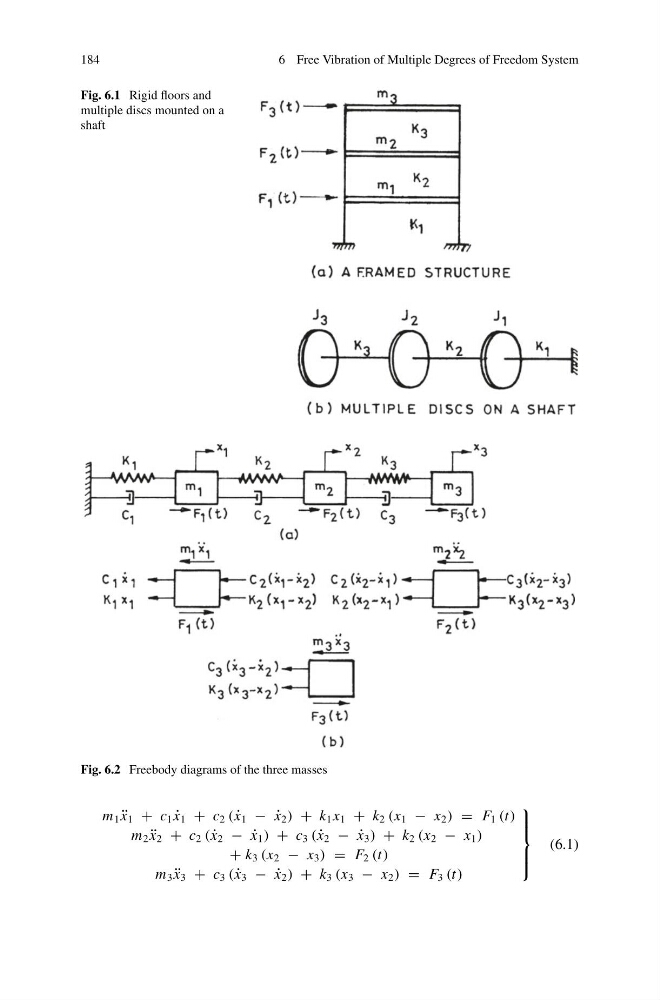
Fig. 6.1 Rigid floors and
multiple discs mounted on a
shaft
Fig. 6.2 Freebody diagrams of the three masses
m 1 ¨
x 1 + c 1 ˙
x 1 + c 2 ( ˙
x 1 − ˙
x 2 ) + k 1 x 1 + k 2 (x 1 − x 2 ) = F 1 (t)
m 2 ¨
x 2 + c 2 ( ˙
x 2 − ˙
x 1 ) + c 3 ( ˙
x 2 − ˙
x 3 ) + k 2 (x 2 − x 1 )
+ k 3 (x 2 − x 3 ) = F 2 (t)
m 3 ¨
x 3 + c 3 ( ˙
x 3 − ˙
x 2 ) + k 3 (x 3 − x 2 ) = F 3 (t)
⎫
⎪ ⎪ ⎬
⎪ ⎪ ⎭
(6.1)