

3 Symmetries in Classical Field Theory
13
with g a diffeomorphism of R
n of class C
2 and J ϕ the Jacobian matrix of g. Such
symmetries are called internal symmetries, since they commute with space and time
translations.
5
Under general regularity assumptions on the potential, such that for infinitely
differentiable initial data the corresponding solution of (3.1) is of class C
2 in the
variables x and t, one gets a characterization of the internal symmetries of the system
(3.1).
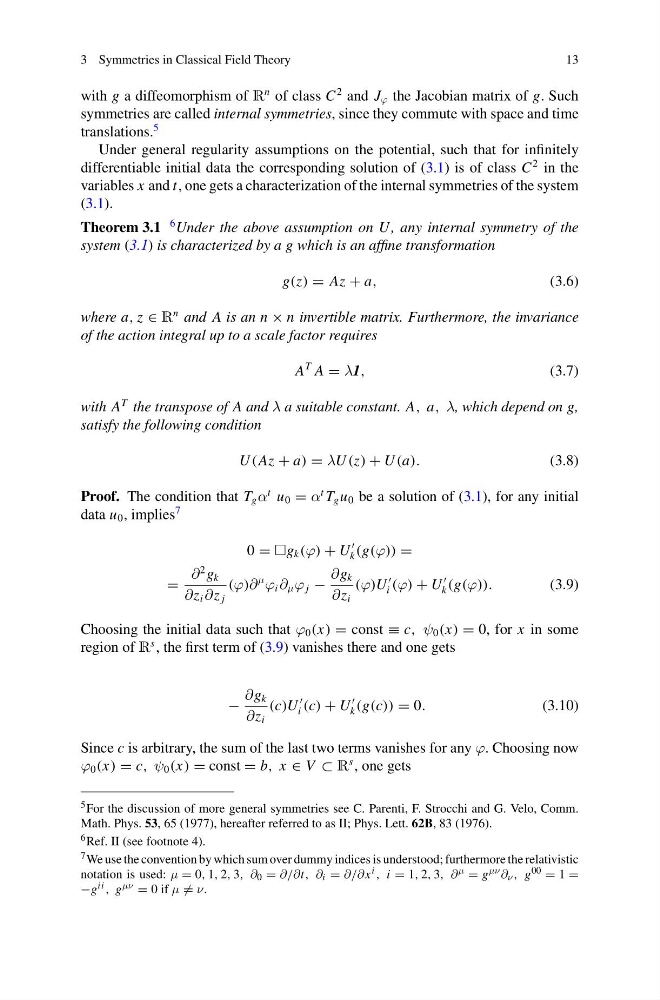
Theorem 3.1
6 Under the above assumption on U , any internal symmetry of the
system (3.1) is characterized by a g which is an affine transformation
g(z) = Az + a,
(3.6)
where a, z ∈ R
n and A is an n × n invertible matrix. Furthermore, the invariance
of the action integral up to a scale factor requires
A
T A = λ1,
(3.7)
with A
T the transpose of A and λ a suitable constant. A, a, λ, which depend on g,
satisfy the following condition
U (Az + a) = λU (z) + U (a).
(3.8)
Proof. The condition that T g α
t u 0 = α
t T g u 0 be a solution of (3.1), for any initial
data u 0 , implies
7
0 = g k (ϕ) + U
k (g(ϕ)) =
=
∂
2 g k
∂z i ∂z j
(ϕ)∂
μ
ϕ i ∂ μ ϕ j −
∂g k
∂z i
(ϕ)U
i (ϕ) + U
k (g(ϕ)).
(3.9)
Choosing the initial data such that ϕ 0 (x) = const ≡ c, ψ 0 (x) = 0, for x in some
region of R
s , the first term of (3.9) vanishes there and one gets
−
∂g k
∂z i
(c)U
i (c) + U
k (g(c)) = 0.
(3.10)
Since c is arbitrary, the sum of the last two terms vanishes for any ϕ. Choosing now
ϕ 0 (x) = c, ψ 0 (x) = const = b, x ∈ V ⊂ R
s , one gets
5 For the discussion of more general symmetries see C. Parenti, F. Strocchi and G. Velo, Comm.
Math. Phys. 53, 65 (1977), hereafter referred to as II; Phys. Lett. 62B, 83 (1976).
6 Ref. II (see footnote 4).
7 We use the convention by which sum over dummy indices is understood; furthermore the relativistic
notation is used: μ = 0, 1, 2, 3, ∂ 0 = ∂/∂t, ∂ i = ∂/∂x i , i = 1, 2, 3, ∂ μ = g μν ∂ ν , g 00 = 1 =
−g ii , g μν = 0 if μ = ν.