

Nonlinear Dynamics of Resonant Microelectromechanical System (MEMS): A Review
71
4.3 Nonlinearity in Sensing System
Different response parameters like amplitude, phase, etc. are used in various ways
in a resonant MEMS device. This requires sensing of the pertinent quantity with
the help of suitable sensing device. Often the resolution of the MEMS device gets
limited by the limitation of the sensing device. Different types of sensors are used,
like capacitive sensor, piezoresistive sensor and optical sensor. It is desirable that
the sensor should be linear for wide range of input. In practice they often show
nonlinearity.
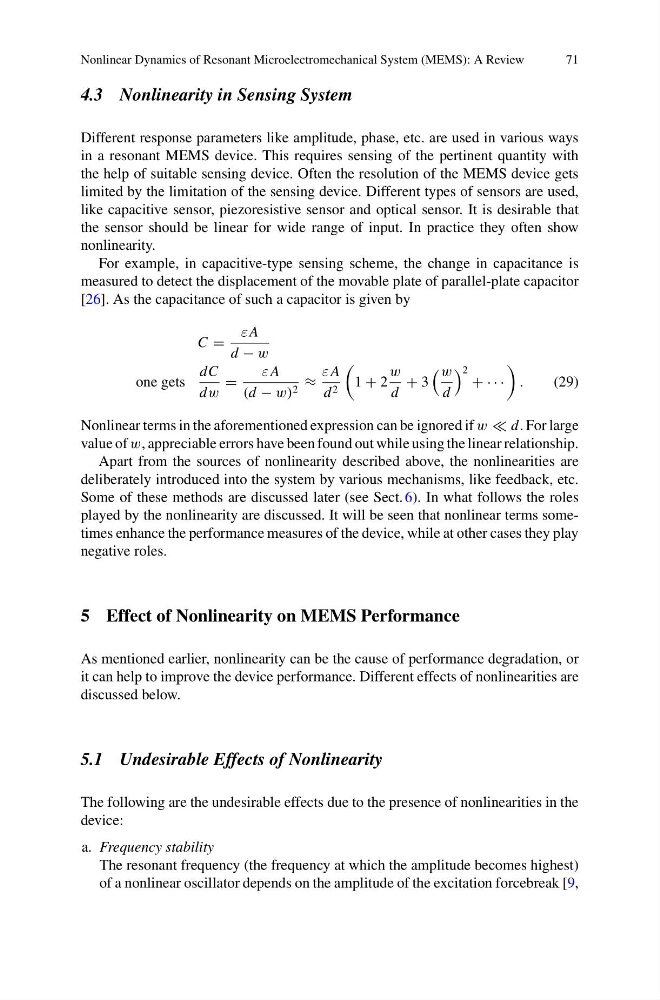
For example, in capacitive-type sensing scheme, the change in capacitance is
measured to detect the displacement of the movable plate of parallel-plate capacitor
[26]. As the capacitance of such a capacitor is given by
C =
εA
d − w
one gets
dC
dw
=
εA
(d − w) 2 ≈
εA
d 2
1 + 2
w
d
+ 3
w
d
2 + · · ·
.
(29)
Nonlinear terms in the aforementioned expression can be ignored if w d. For large
value of w, appreciable errors have been found out while using the linear relationship.
Apart from the sources of nonlinearity described above, the nonlinearities are
deliberately introduced into the system by various mechanisms, like feedback, etc.
Some of these methods are discussed later (see Sect. 6). In what follows the roles
played by the nonlinearity are discussed. It will be seen that nonlinear terms sometimes enhance the performance measures of the device, while at other cases they play
negative roles.
5 Effect of Nonlinearity on MEMS Performance
As mentioned earlier, nonlinearity can be the cause of performance degradation, or
it can help to improve the device performance. Different effects of nonlinearities are
discussed below.
5.1 Undesirable Effects of Nonlinearity
The following are the undesirable effects due to the presence of nonlinearities in the
device:
a. Frequency stability
The resonant frequency (the frequency at which the amplitude becomes highest)
of a nonlinear oscillator depends on the amplitude of the excitation forcebreak [9,