

374
W. Chang et al.
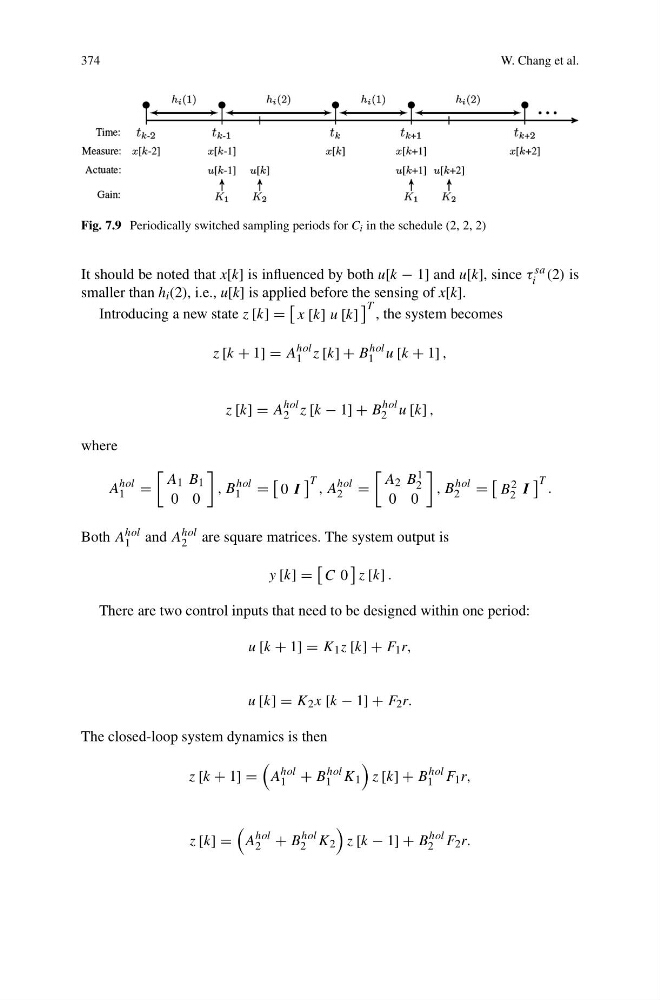
Fig. 7.9 Periodically switched sampling periods for C i in the schedule (2, 2, 2)
It should be noted that x[k] is influenced by both u[k − 1] and u[k], since τ sa
i (2) is
smaller than h i (2), i.e., u[k] is applied before the sensing of x[k].
Introducing a new state z [k] =
x [k] u [k]
T , the system becomes
z [k + 1] = A
hol
1 z [k] + B
hol
1 u [k + 1] ,
z [k] = A
hol
2 z [k − 1] + B
hol
2 u [k] ,
where
A
hol
1 =
A 1 B 1
0 0
, B
hol
1 =
0 I
T , A
hol
2 =
A 2 B 1
2
0 0
, B
hol
2 =
B 2
2 I
T .
Both A hol
1 and A hol
2 are square matrices. The system output is
y [k] =
C 0
z [k] .
There are two control inputs that need to be designed within one period:
u [k + 1] = K 1 z [k] + F 1 r,
u [k] = K 2 x [k − 1] + F 2 r.
The closed-loop system dynamics is then
z [k + 1] =
A
hol
1 + B
hol
1 K 1
z [k] + B
hol
1 F 1 r,
z [k] =
A
hol
2 + B
hol
2 K 2
z [k − 1] + B
hol
2 F 2 r.