

6 Lattice and the Continuum
51
fixed spatial element of volume V (in the one-dimensional case x), which we
observe in a predetermined position x, a constant position of our reference system. We therefore have to calculate which statement of the Newtonian inertia term
d P/dt =
d
dt
((m v) results in a fixed static volume V . These calculations will be
shown thoroughly in the appendix, in Chap. 25, where we will generally concern
ourselves with this problem. The passing to the limit (66) is a special case of the
derived passing to the limit (324). Here, we will have to be satisfied with the following statement. This limit is to be understood within the meaning of the elasticity
theory, which alone interests us in the following. This means, in the so-called total
time derivative for the velocity of matter v, dv/dt = ∂v/∂t + (∂v/∂x) (dx/dt) ,
the second, non-linear term is simply dropped, and in the same way, for the quantity
v = ds/dt = ∂s/∂t + (∂s/∂x) (dx/dt) only the partial derivative with respect to
time for the displacement s should be considered. This leads to the approximation
in (66). For the mathematics, we refer to Chap. 25.
Here, we want to point out that the application of the linear elasticity theory is
not always justified. For example, using linear elasticity, we cannot calculate the
elastic deformations that cause a so-called dislocation (see Chap. 7) in its immediate
neighbourhood. Nevertheless, the continuation of our considerations will not be
affected by this limitation. With the exception of Chaps. 25–27, where we will be
dealing explicitly with linear problems of the theory of elasticity, we will be occupied
only with plastic deformations (cf. Chap. 7), especially with the deformations of the
dislocation line under the influence of the non-linear lattice potential, for example the
creation and motion of so-called kinks in the dislocation line, see Chaps. 9 and 10.
We insert (66) in (63) and find by cancelling x,
ρ
∂
∂t
∂s(x, t)
∂t
=
∂τ (x, t)
∂x
.
(67)
(However, in a three-dimensional lattice we get the Eq. (325) from Chap. 25.)
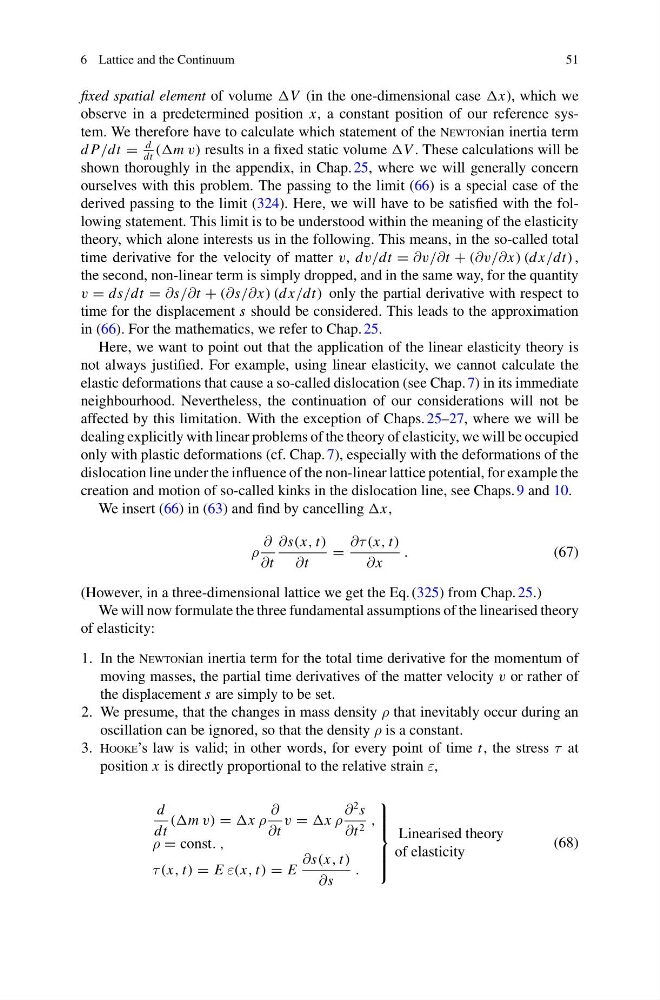
We will now formulate the three fundamental assumptions of the linearised theory
of elasticity:
1. In the Newtonian inertia term for the total time derivative for the momentum of
moving masses, the partial time derivatives of the matter velocity v or rather of
the displacement s are simply to be set.
2. We presume, that the changes in mass density ρ that inevitably occur during an
oscillation can be ignored, so that the density ρ is a constant.
3. Hooke’s law is valid; in other words, for every point of time t, the stress τ at
position x is directly proportional to the relative strain ε,
d
dt
((m v) = x ρ
∂
∂t
v = x ρ
∂
2 s
∂t 2 ,
ρ = const. ,
τ (x, t) = E ε(x, t) = E
∂s(x, t)
∂s
.
⎫
⎪ ⎪ ⎪ ⎬
⎪ ⎪ ⎪ ⎭
Linearised theory
of elasticity
(68)