

61
2.5. Axial symmetry
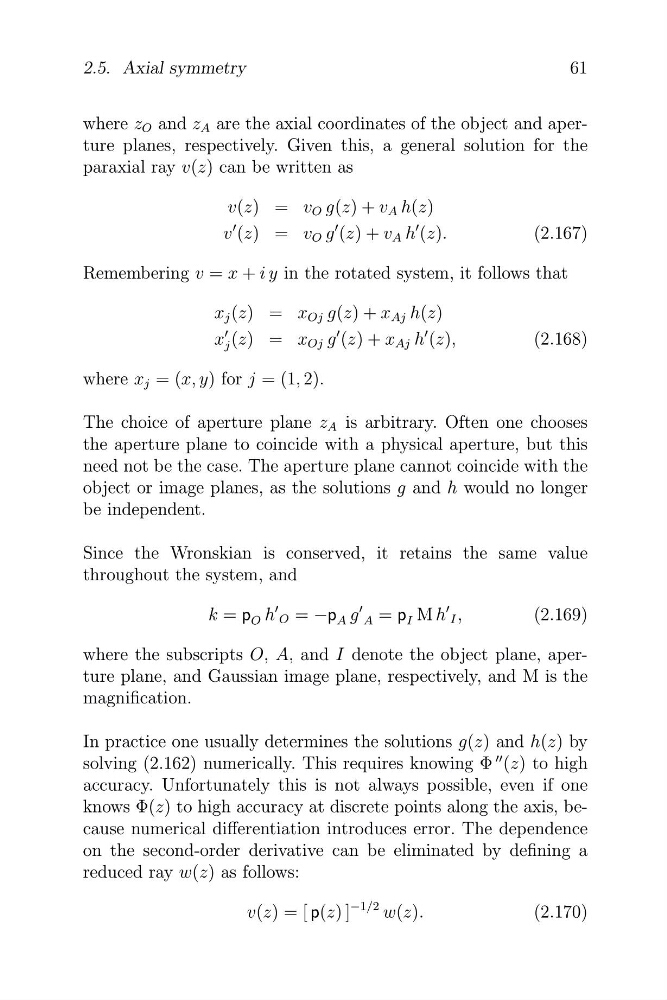
where z O and z A are the axial coordinates of the object and aperture planes, respectively. Given this, a general solution for the
paraxial ray v(z) can be written as
v(z) = v O g(z) + v A h(z)
v
� (z) = v O g
� (z) + v A h
� (z).
(2.167)
Remembering v = x + i y in the rotated system, it follows that
x j (z) = x Oj g(z) + x Aj h(z)
x j
� (z) = x Oj g
� (z) + x Aj h
� (z),
(2.168)
where x j = (x, y) for j = (1, 2).
The choice of aperture plane z A is arbitrary. Often one chooses
the aperture plane to coincide with a physical aperture, but this
need not be the case. The aperture plane cannot coincide with the
object or image planes, as the solutions g and h would no longer
be independent.
Since the Wronskian is conserved, it retains the same value
throughout the system, and
k = p O h
�
O = −p A g
�
A = p I M h
�
I ,
(2.169)
where the subscripts O, A, and I denote the object plane, aperture plane, and Gaussian image plane, respectively, and M is the
magnification.
In practice one usually determines the solutions g(z) and h(z) by
solving (2.162) numerically. This requires knowing Φ
�� (z) to high
accuracy. Unfortunately this is not always possible, even if one
knows Φ(z) to high accuracy at discrete points along the axis, because numerical differentiation introduces error. The dependence
on the second-order derivative can be eliminated by defining a
reduced ray w(z) as follows:
v(z) = [ p(z) ]
−1/2 w(z).
(2.170)