

150
6 Dynamics of Quantum Mechanical Macroscopic Systems
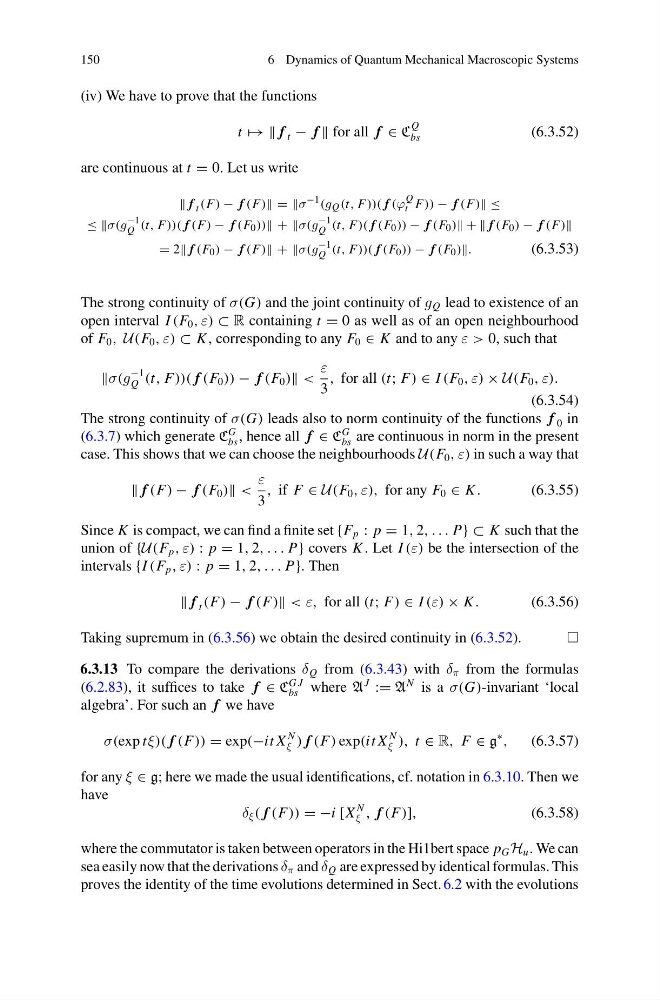
(iv) We have to prove that the functions
t → → f t − f for all f ∈ C
Q
bs
(6.3.52)
are continuous at t = 0. Let us write
f t (F) − f (F) = =σ
−1 (g Q (t, F))( f (ϕ
Q
t F)) − f (F) ≤
≤ ≤σ(g
−1
Q (t, F))( f (F) − f (F 0 )) + +σ(g
−1
Q (t, F)( f (F 0 )) − f (F 0 ) + + f (F 0 ) − f (F)
= 2 f (F 0 ) − f (F) + +σ(g
−1
Q (t, F))( f (F 0 )) − f (F 0 ).
(6.3.53)
The strong continuity of σ(G) and the joint continuity of g Q lead to existence of an
open interval I (F 0 , ε) ⊂ R containing t = 0 as well as of an open neighbourhood
of F 0 , U(F 0 , ε) ⊂ K , corresponding to any F 0 ∈ K and to any ε > 0, such that
σ(g
−1
Q (t, F))( f (F 0 )) − f (F 0 ) <
ε
3
, for all (t; F) ∈ I (F 0 , ε) × U(F 0 , ε).
(6.3.54)
The strong continuity of σ(G) leads also to norm continuity of the functions f 0 in
(6.3.7) which generate C
G
bs , hence all f ∈ C
G
bs are continuous in norm in the present
case. This shows that we can choose the neighbourhoods U(F 0 , ε) in such a way that
f (F) − f (F 0 ) <
ε
3
, if F ∈ U(F 0 , ε), for any F 0 ∈ K .
(6.3.55)
Since K is compact, we can find a finite set {F p : p = 1, 2, . . . P} ⊂ K such that the
union of {U(F p , ε) : p = 1, 2, . . . P} covers K . Let I (ε) be the intersection of the
intervals {I (F p , ε) : p = 1, 2, . . . P}. Then
f t (F) − f (F) < ε, for all (t; F) ∈ I (ε) × K .
(6.3.56)
Taking supremum in (6.3.56) we obtain the desired continuity in (6.3.52).
6.3.13 To compare the derivations δ Q from (6.3.43) with δ π from the formulas
(6.2.83), it suffices to take f ∈ C
G J
bs where A
J
:= A
N is a σ(G)-invariant ‘local
algebra’. For such an f we have
σ(exp tξ)( f (F)) = exp(−it X
N
ξ ) f (F) exp(it X
N
ξ ), t ∈ R, F ∈ g
∗
,
(6.3.57)
for any ξ ∈ g; here we made the usual identifications, cf. notation in 6.3.10. Then we
have
δ ξ ( f (F)) = −i [X
N
ξ , f (F)],
(6.3.58)
where the commutator is taken between operators in the Hi1bert space p G H u . We can
sea easily now that the derivations δ π and δ Q are expressed by identical formulas. This
proves the identity of the time evolutions determined in Sect. 6.2 with the evolutions