

126
6 Dynamics of Quantum Mechanical Macroscopic Systems
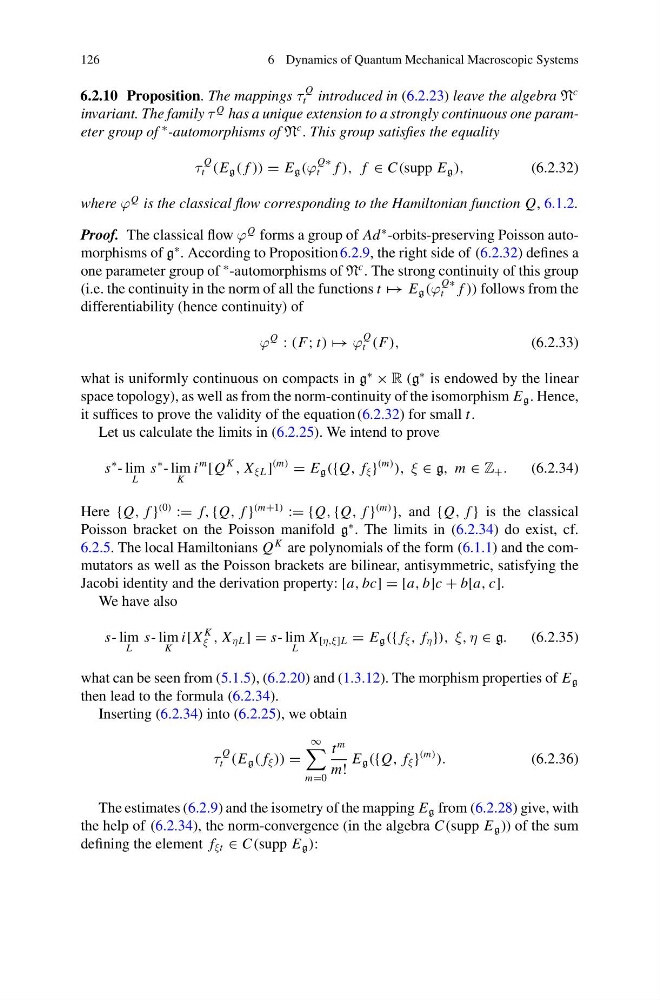
6.2.10 Proposition. The mappings τ
Q
t introduced in (6.2.23) leave the algebra N
c
invariant. The family τ
Q has a unique extension to a strongly continuous one parameter group of
∗ -automorphisms of N
c . This group satisfies the equality
τ
Q
t (E g ( f )) = E g (ϕ
Q∗
t f ), f ∈ C(supp E g ),
(6.2.32)
where ϕ
Q is the classical flow corresponding to the Hamiltonian function Q, 6.1.2.
Proof. The classical flow ϕ
Q forms a group of Ad
∗ -orbits-preserving Poisson automorphisms of g
∗ . According to Proposition 6.2.9, the right side of (6.2.32) defines a
one parameter group of
∗ -automorphisms of N
c . The strong continuity of this group
(i.e. the continuity in the norm of all the functions t → E g (ϕ
Q∗
t f )) follows from the
differentiability (hence continuity) of
ϕ
Q
: (F; t) → ϕ
Q
t (F),
(6.2.33)
what is uniformly continuous on compacts in g
∗
× R (g
∗ is endowed by the linear
space topology), as well as from the norm-continuity of the isomorphism E g . Hence,
it suffices to prove the validity of the equation (6.2.32) for small t.
Let us calculate the limits in (6.2.25). We intend to prove
s
∗ - lim
L
s
∗ - lim
K
i
m
[Q
K
, X ξ L ]
(m)
= E g ({Q, f ξ }
(m)
), ξ ∈ g, m ∈ Z + .
(6.2.34)
Here {Q, f }
(0)
:= f, {Q, f }
(m+1)
:= {Q, {Q, f }
(m)
}, and {Q, f } is the classical
Poisson bracket on the Poisson manifold g
∗ . The limits in (6.2.34) do exist, cf.
6.2.5. The local Hamiltonians Q
K are polynomials of the form (6.1.1) and the commutators as well as the Poisson brackets are bilinear, antisymmetric, satisfying the
Jacobi identity and the derivation property: [a, bc] = [a, b]c + b[a, c].
We have also
s- lim
L
s- lim
K
i[X
K
ξ , X ηL ] = s- lim
L
X [η,ξ]L = E g ({ f ξ , f η }), ξ, η ∈ g.
(6.2.35)
what can be seen from (5.1.5), (6.2.20) and (1.3.12). The morphism properties of E g
then lead to the formula (6.2.34).
Inserting (6.2.34) into (6.2.25), we obtain
τ
Q
t (E g ( f ξ )) =
∞
m=0
t
m
m!
E g ({Q, f ξ }
(m)
).
(6.2.36)
The estimates (6.2.9) and the isometry of the mapping E g from (6.2.28) give, with
the help of (6.2.34), the norm-convergence (in the algebra C(supp E g )) of the sum
defining the element f ξt ∈ C(supp E g ):