

Also, if possible, control structures should be simplified as much as possible due
to the strict timing requirements and as small as possible overheads. One promising
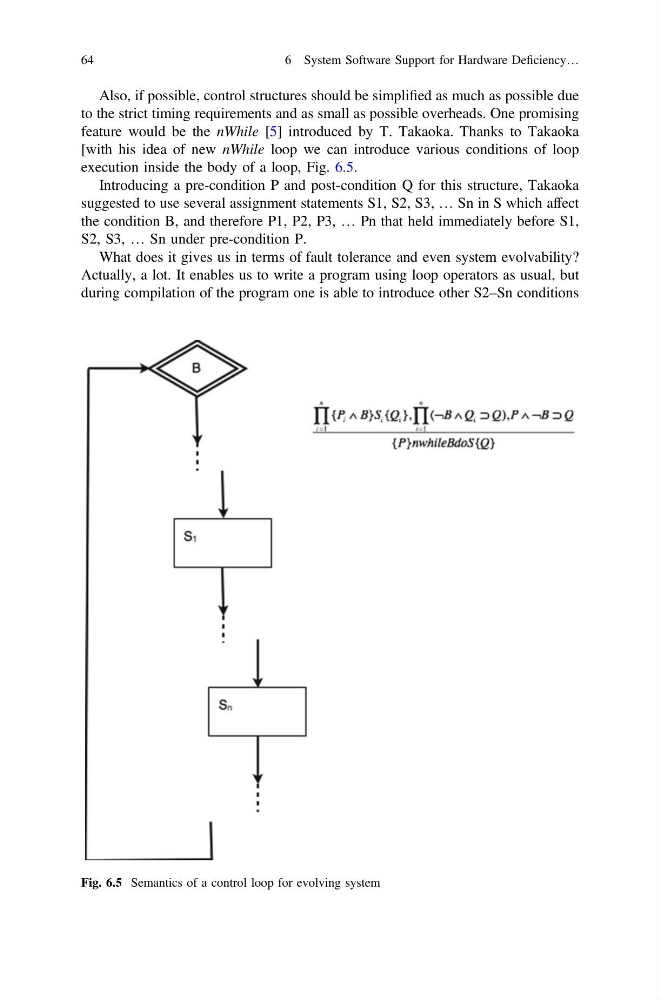
feature would be the nWhile [5] introduced by T. Takaoka. Thanks to Takaoka
[with his idea of new nWhile loop we can introduce various conditions of loop
execution inside the body of a loop, Fig. 6.5.
Introducing a pre-condition P and post-condition Q for this structure, Takaoka
suggested to use several assignment statements S1, S2, S3, … Sn in S which affect
the condition B, and therefore P1, P2, P3, … Pn that held immediately before S1,
S2, S3, … Sn under pre-condition P.
What does it gives us in terms of fault tolerance and even system evolvability?
Actually, a lot. It enables us to write a program using loop operators as usual, but
during compilation of the program one is able to introduce other S2–Sn conditions
Fig. 6.5 Semantics of a control loop for evolving system
64
6 System Software Support for Hardware Deficiency…