

(a) Minimization of the state space that needs to be saved before each instruction’s
execution;
(b) Simplest possible graphs of predicates, addresses, and data for program;
(c) Control of execution when hardware state changes during repetitive operators.
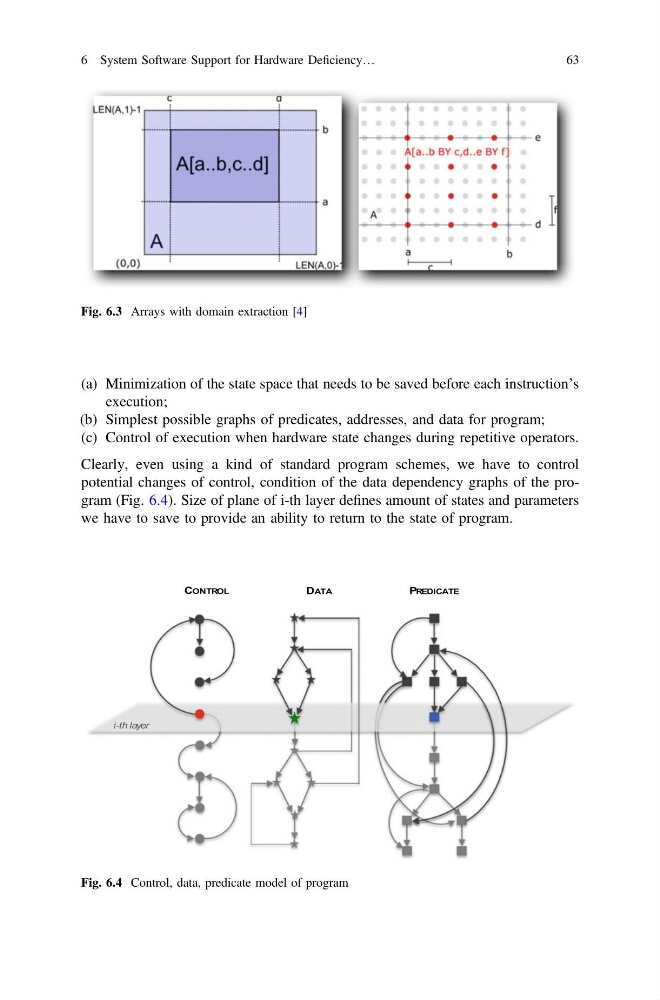
Clearly, even using a kind of standard program schemes, we have to control
potential changes of control, condition of the data dependency graphs of the program (Fig. 6.4). Size of plane of i-th layer defines amount of states and parameters
we have to save to provide an ability to return to the state of program.
Fig. 6.3 Arrays with domain extraction [4]
Fig. 6.4 Control, data, predicate model of program
6 System Software Support for Hardware Deficiency…
63