

5.8 Numerical Algorithms
95
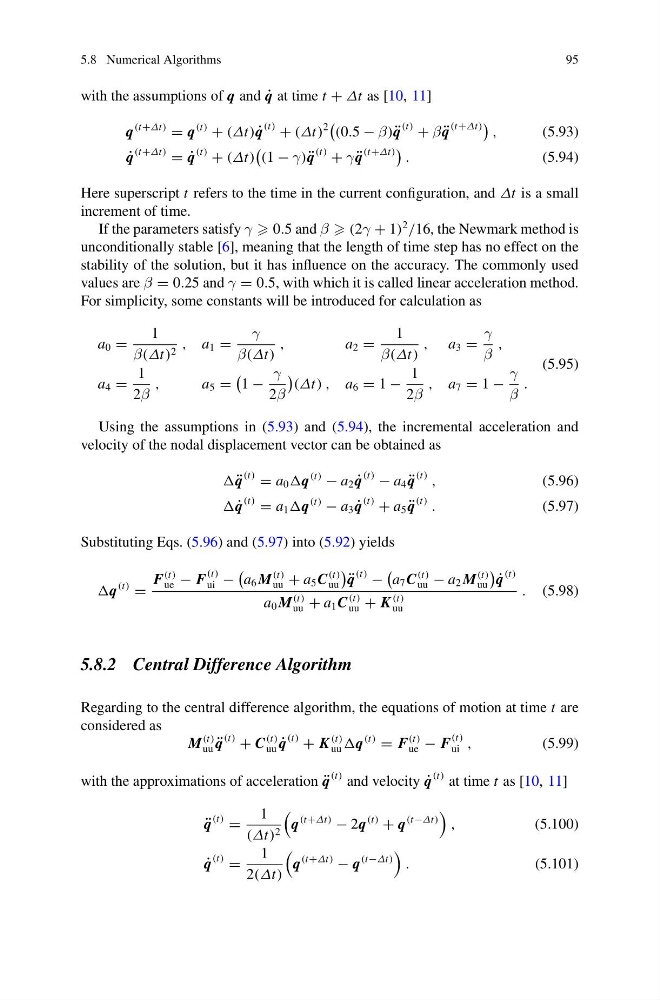
with the assumptions of q and ˙
q at time t + Δt as [10, 11]
q
(t+Δt)
= q
(t)
+ (Δt) ˙
q
(t) + (Δt)
2
(0.5 − β) ¨
q
(t) + β ¨
q
(t+Δt) ,
(5.93)
˙
q
(t+Δt) = ˙
q
(t) + (Δt)
(1 − γ) ¨
q
(t) + γ ¨
q
(t+Δt) .
(5.94)
Here superscript t refers to the time in the current configuration, and Δt is a small
increment of time.
If the parameters satisfy γ 0.5 and β (2γ + 1)
2
/16, the Newmark method is
unconditionally stable [6], meaning that the length of time step has no effect on the
stability of the solution, but it has influence on the accuracy. The commonly used
values are β = 0.25 and γ = 0.5, with which it is called linear acceleration method.
For simplicity, some constants will be introduced for calculation as
a 0 =
1
β(Δt) 2 , a 1 =
γ
β(Δt)
,
a 2 =
1
β(Δt)
, a 3 =
γ
β
,
a 4 =
1
2β
,
a 5 =
1 −
γ
2β
(Δt) , a 6 = 1 −
1
2β
, a 7 = 1 −
γ
β
.
(5.95)
Using the assumptions in (5.93) and (5.94), the incremental acceleration and
velocity of the nodal displacement vector can be obtained as
¨
q
(t) = a 0 q
(t)
− a 2 ˙
q
(t) − a 4 ¨
q
(t) ,
(5.96)
˙
q
(t) = a 1 q
(t)
− a 3 ˙
q
(t) + a 5 ¨
q
(t) .
(5.97)
Substituting Eqs. (5.96) and (5.97) into (5.92) yields
q
(t)
=
F
(t)
ue − F
(t)
ui −
a 6 M
(t)
uu + a 5 C
(t)
uu
¨
q
(t) −
a 7 C
(t)
uu − a 2 M
(t)
uu
˙
q
(t)
a 0 M
(t)
uu + a 1 C
(t)
uu + K
(t)
uu
. (5.98)
5.8.2 Central Difference Algorithm
Regarding to the central difference algorithm, the equations of motion at time t are
considered as
M
(t)
uu ¨
q
(t) + C
(t)
uu ˙
q
(t) + K
(t)
uu q
(t)
= F
(t)
ue − F
(t)
ui ,
(5.99)
with the approximations of acceleration ¨
q
(t) and velocity ˙
q
(t) at time t as [10, 11]
¨
q
(t) =
1
(Δt) 2
q
(t+Δt)
− 2q
(t)
+ q
(t−Δt)
,
(5.100)
˙
q
(t) =
1
2(Δt)
q
(t+Δt)
− q
(t−Δt)
.
(5.101)