

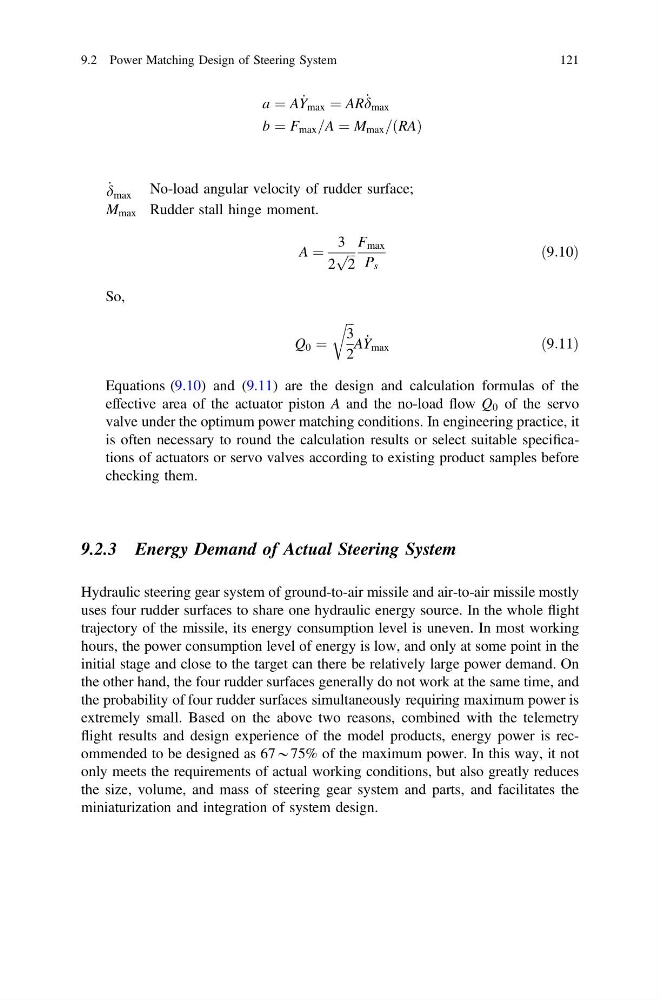
a ¼ A _
Y max ¼ AR _
d max
b ¼ F max =A ¼ M max = RA
ð Þ
_
d max No-load angular velocity of rudder surface;
M max Rudder stall hinge moment.
A ¼
3
2
ffiffi ffi
2
p
F max
P s
ð9:10Þ
So,
Q 0 ¼
ffiffi ffi
3
2
r
A _
Y max
ð9:11Þ
Equations (9.10) and (9.11) are the design and calculation formulas of the
effective area of the actuator piston A and the no-load flow Q 0 of the servo
valve under the optimum power matching conditions. In engineering practice, it
is often necessary to round the calculation results or select suitable specifications of actuators or servo valves according to existing product samples before
checking them.
9.2.3 Energy Demand of Actual Steering System
Hydraulic steering gear system of ground-to-air missile and air-to-air missile mostly
uses four rudder surfaces to share one hydraulic energy source. In the whole flight
trajectory of the missile, its energy consumption level is uneven. In most working
hours, the power consumption level of energy is low, and only at some point in the
initial stage and close to the target can there be relatively large power demand. On
the other hand, the four rudder surfaces generally do not work at the same time, and
the probability of four rudder surfaces simultaneously requiring maximum power is
extremely small. Based on the above two reasons, combined with the telemetry
flight results and design experience of the model products, energy power is recommended to be designed as 67*75% of the maximum power. In this way, it not
only meets the requirements of actual working conditions, but also greatly reduces
the size, volume, and mass of steering gear system and parts, and facilitates the
miniaturization and integration of system design.
9.2 Power Matching Design of Steering System
121