

2.5 Basics of Component Modeling in WSM
71
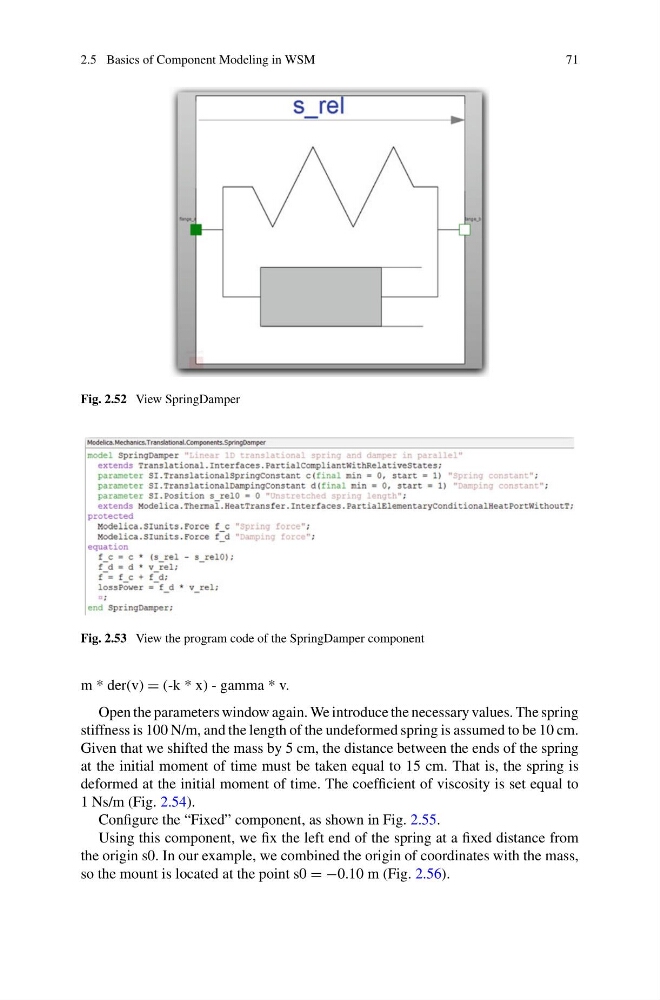
Fig. 2.52 View SpringDamper
Fig. 2.53 View the program code of the SpringDamper component
m * der(v) = (-k * x) - gamma * v.
Open the parameters window again. We introduce the necessary values. The spring
stiffness is 100 N/m, and the length of the undeformed spring is assumed to be 10 cm.
Given that we shifted the mass by 5 cm, the distance between the ends of the spring
at the initial moment of time must be taken equal to 15 cm. That is, the spring is
deformed at the initial moment of time. The coefficient of viscosity is set equal to
1 Ns/m (Fig. 2.54).
Configure the “Fixed” component, as shown in Fig. 2.55.
Using this component, we fix the left end of the spring at a fixed distance from
the origin s0. In our example, we combined the origin of coordinates with the mass,
so the mount is located at the point s0 = −0.10 m (Fig. 2.56).