

256
6 Hierarchical Component Models
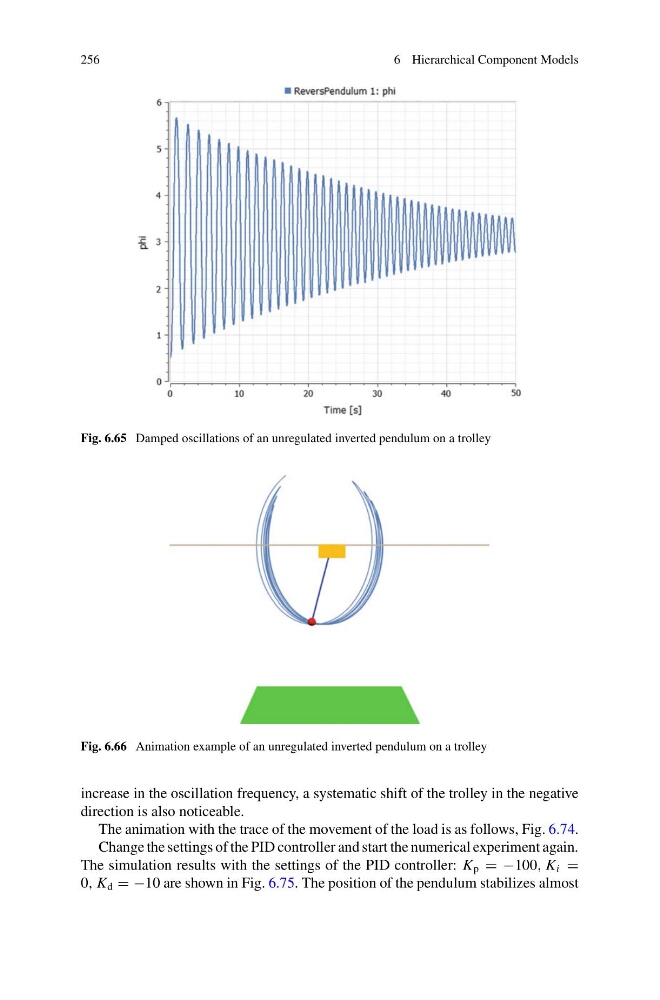
Fig. 6.65 Damped oscillations of an unregulated inverted pendulum on a trolley
Fig. 6.66 Animation example of an unregulated inverted pendulum on a trolley
increase in the oscillation frequency, a systematic shift of the trolley in the negative
direction is also noticeable.
The animation with the trace of the movement of the load is as follows, Fig. 6.74.
Change the settings of the PID controller and start the numerical experiment again.
The simulation results with the settings of the PID controller: K p = −100, K i =
0, K d = −10 are shown in Fig. 6.75. The position of the pendulum stabilizes almost